Published: DECEMBER 1, 2025
Updated:SEPTEMBER 11, 2026
In Human-Machine Interface(HMI), vision and hearing dominate. Touch (Haptics) is rising as the most direct channel. Breakthroughs in vibrating motors drive this revival. Haptic Actuators evolved from silent alerts to key bridges between digital and human perception.
This report reviews ERM, LRA, Piezoelectric Actuators, and Voice Coil Actuators. We explore applications in consumer electronics, automotive safety, medical robotics, and VR. With 15+ years of experience, TSL MOTOR provides selection advice and market insights.
Wichtigste Erkenntnisse
- ERM motors rotate an eccentric mass, while LRAs generate linear vibration near resonance.
- ERM vibration depends on eccentric mass, offset radius, speed and mounting.
- ERM vibration frequency and force both change with motor speed.
- Mounting stiffness and product mass can significantly change the measured vibration.
- Service life depends on speed, temperature, duty cycle and motor construction.
- Coin, cylindrical, SMD and encapsulated motors suit different installation requirements.
- Final performance should be verified in the assembled product.
Vibrating Electric Motor Basics
What Are Vibrating Electric Motors?
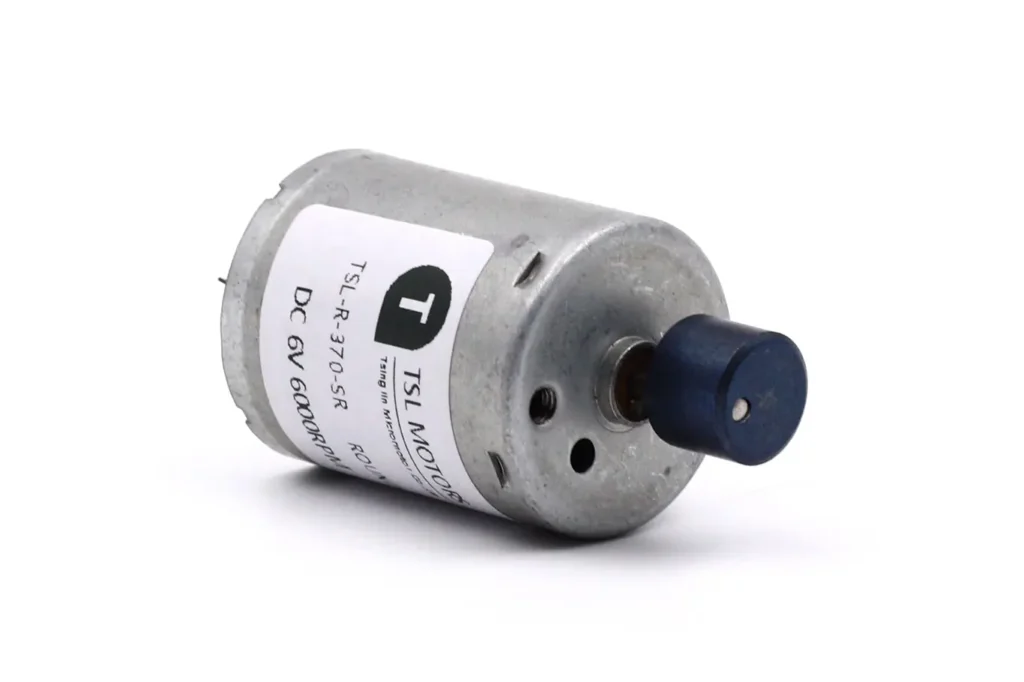
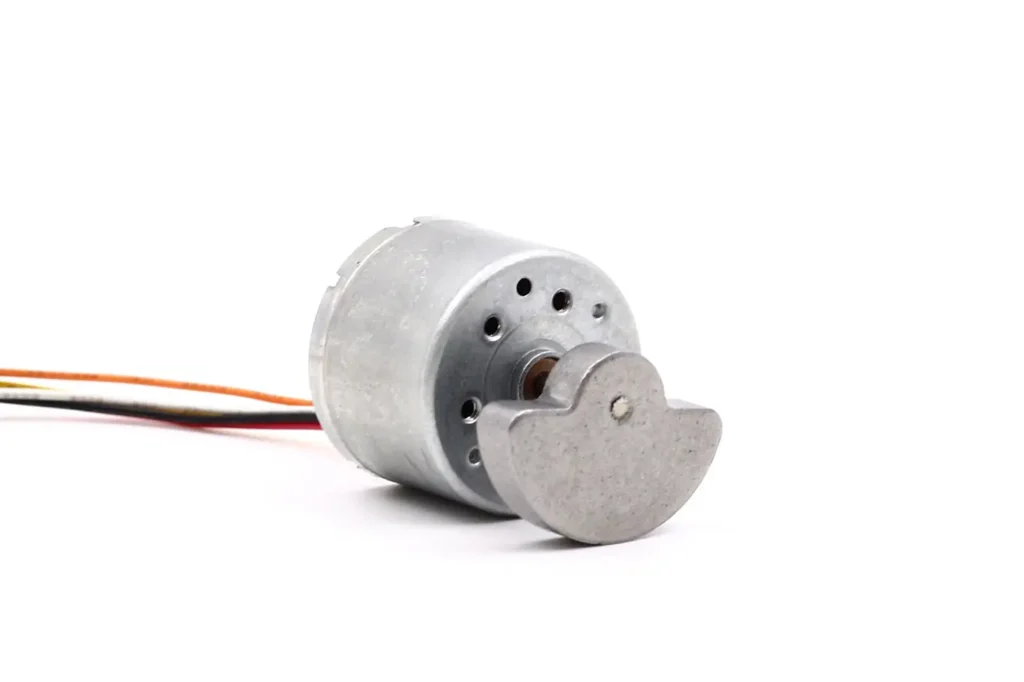
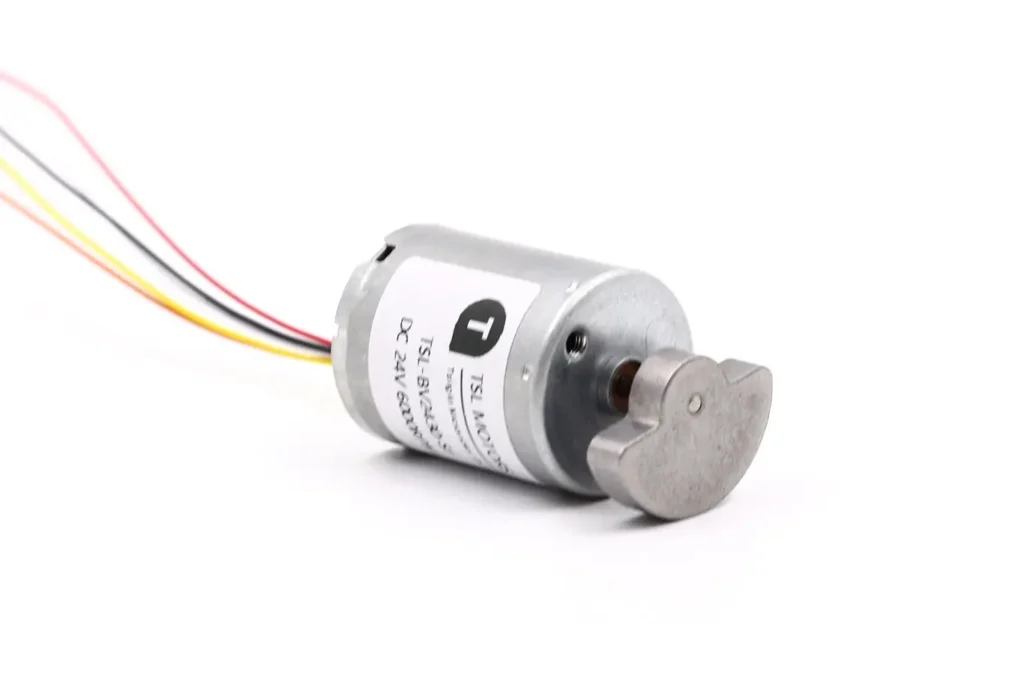
A vibrating electric motor converts electrical energy into periodic mechanical motion. The most common design is the eccentric rotating mass motor, or ERM, which uses a small electric motor to rotate an off-center weight.
The rotating force is transmitted through the motor housing and mounting structure into the product. The term is also used broadly for LRAs and other vibration actuators, although these devices do not all use a conventional rotating motor.
How Vibrating Electric Motors Work?
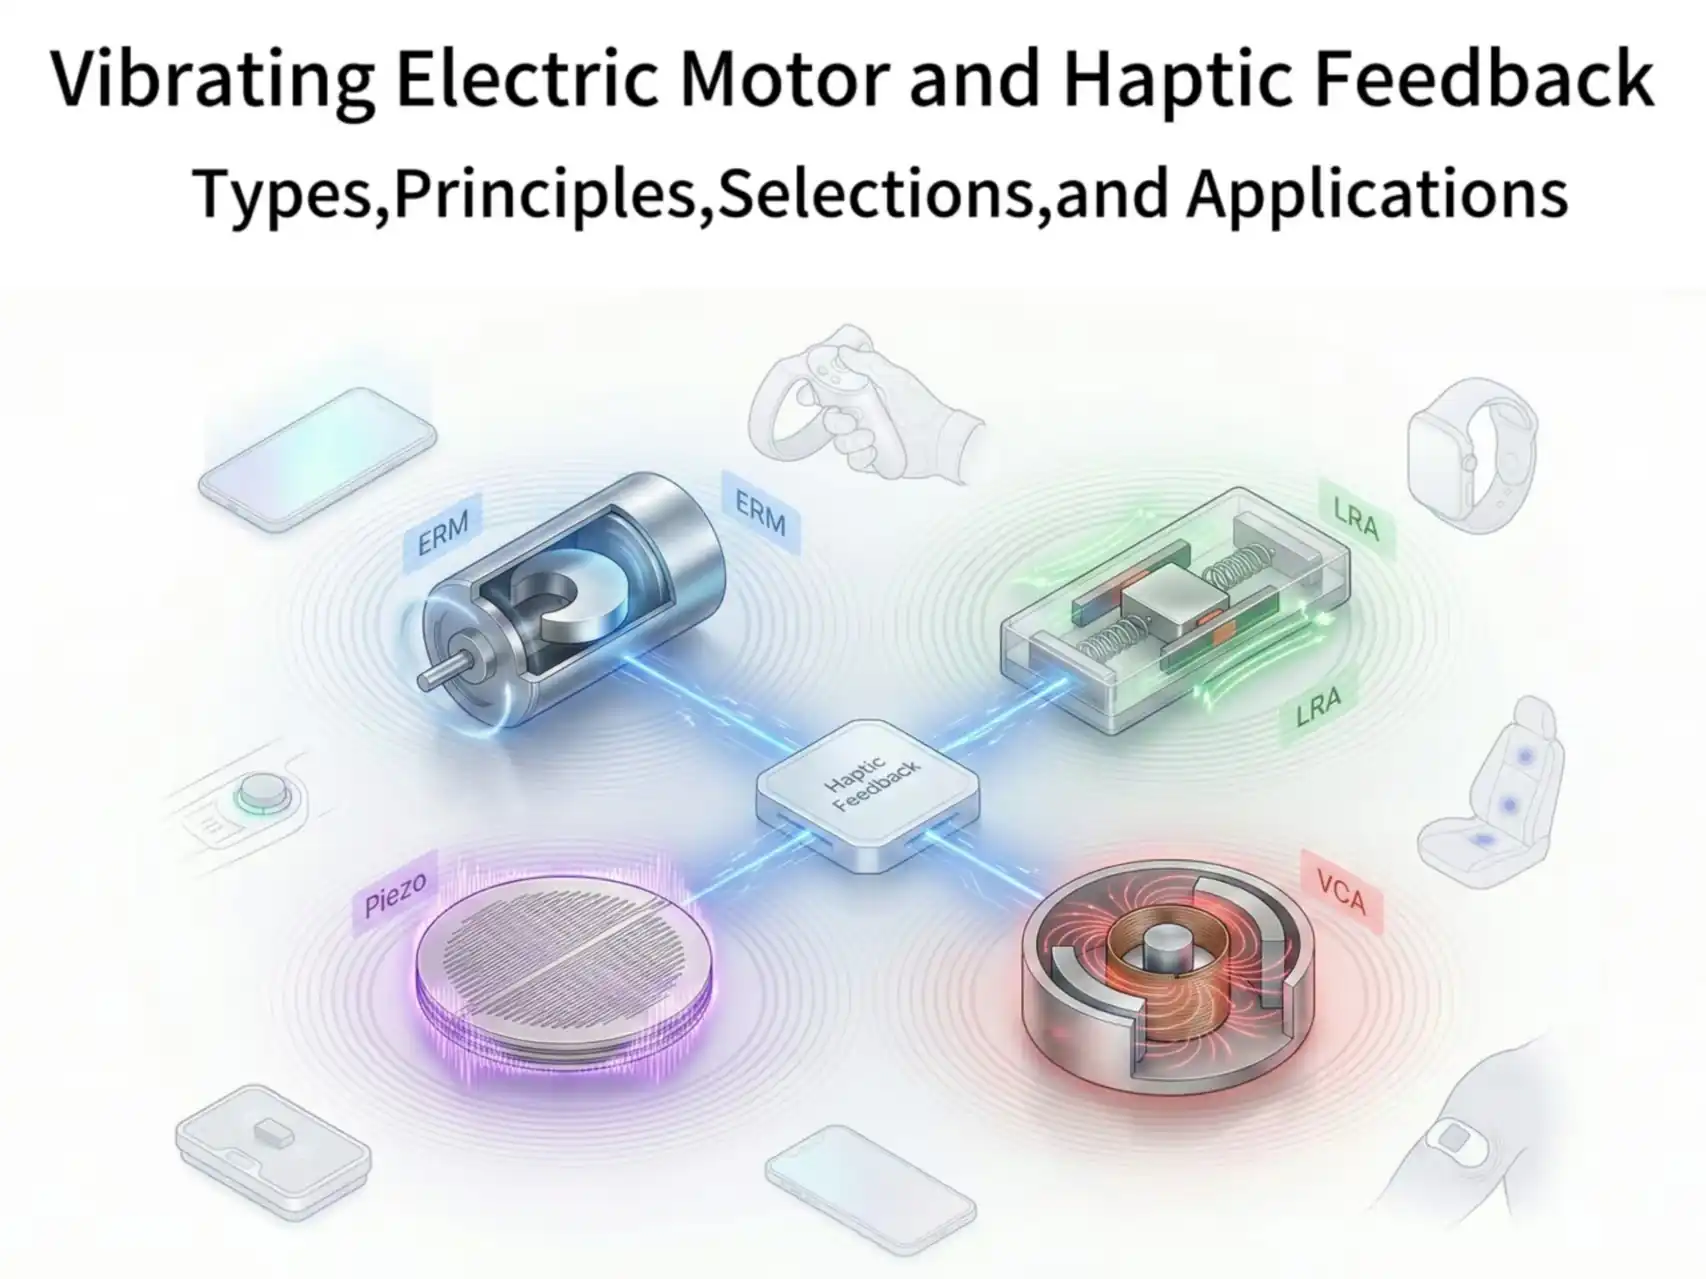
The core function of a vibrating motor is to convert electrical energy into periodic mechanical vibration. Different motor types employ distinct physical mechanisms:
ERM Vibration Motor
Core Principle: Imbalance = Vibration.
Die ERM motor is a DC motor characterized by an eccentric mass fixed to the rotor shaft.
The asymmetric mass distribution generates continuous centrifugal force when rotating. This force causes the motor and its mounted device to vibrate.
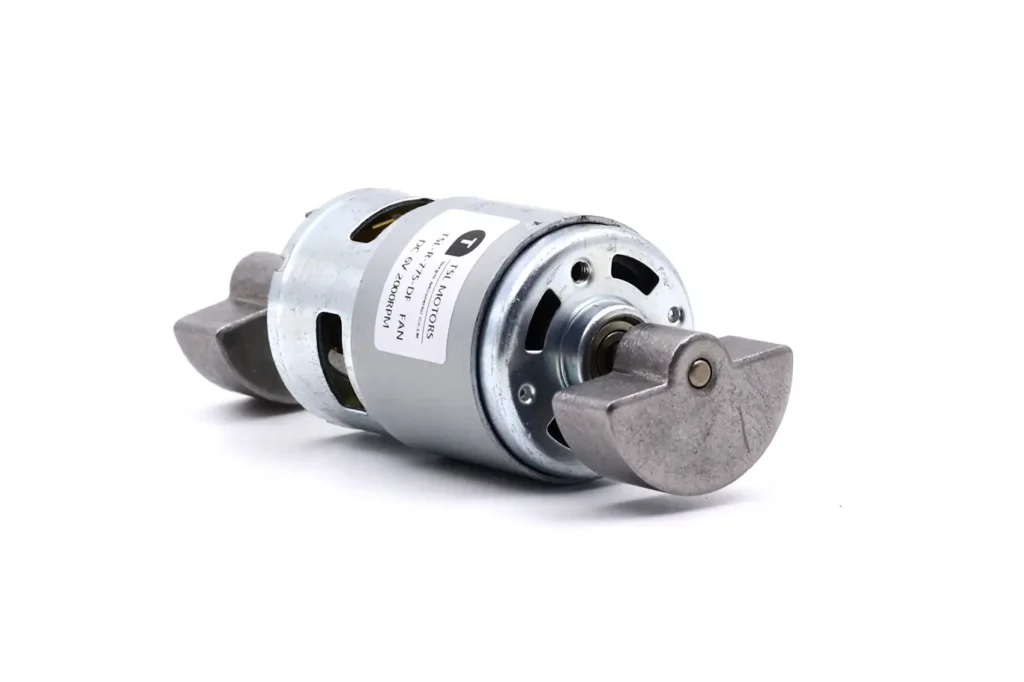
Operating Process:
- Power On: Electrical current energizes the motor windings. In a brushed permanent-magnet ERM motor, current reaches the rotating armature through the brushes and commutator.
- Rotor Rotation: The magnetic field drives the rotor and shaft to spin at high speed.
- Centrifugal Force: The off-center mass generates a centrifugal force that constantly changes direction.
- Vibration: This force transfers to the motor casing and then to the device, creating periodic vibration.
LRA (Linear Resonant Actuator)
Die LRA is a vibrating motor that generates precise haptic feedback. It oscillates back and forth at a resonant frequency using a spring-mass system. Unlike traditional ERM motors, the LRA relies on linear, non-rotational vibration.
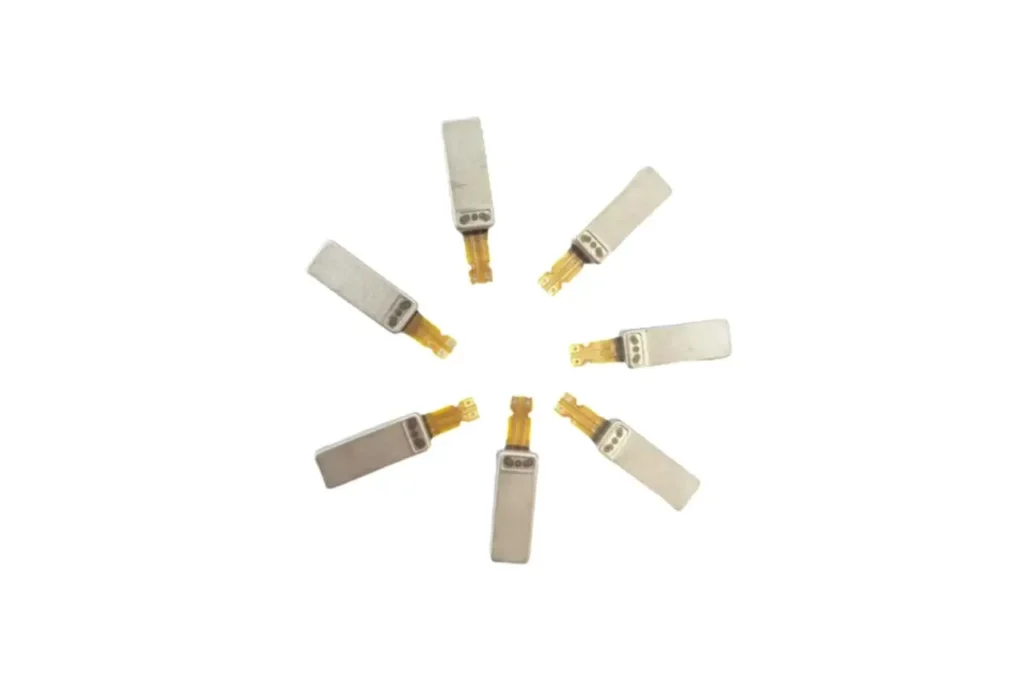
Driving Process:
- AC Drive: AC current passing through the coil generates an alternating magnetic field.
- Magnetic Interaction: The alternating field interacts with the permanent magnet’s field. This pushes the magnet to oscillate along a single axis.
- Resonance Effect: When the drive frequency matches the system’s natural resonant frequency, the amplitude is maximized, achieving peak efficiency.
- Haptic Feedback: This linear vibration transfers through the casing, delivering clear and rapid haptic feedback.
Piezoelectric Actuator
Piezoelectric Actuator:When an electric field is applied across a piezoelectric material (e.g., ceramic or crystal), the material undergoes a minute mechanical deformation (expansion or contraction).
This deformation is directly converted into displacement or vibration. It drives external structures or creates haptic feedback.
Conversely, the material generates an electric charge when subjected to mechanical stress. Thus, it can function as both an actuator and a sensor.
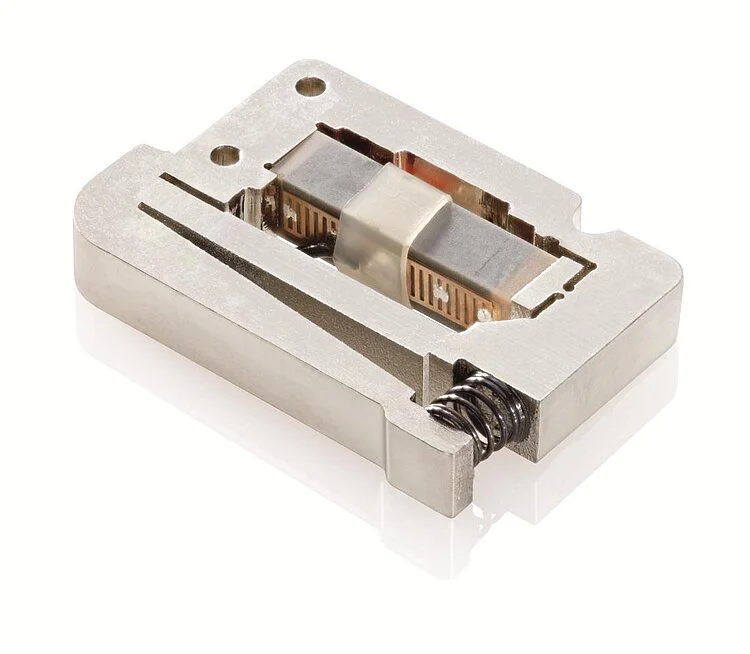
Driving Process:
- Voltage is applied across the piezoelectric material.
- The material produces a tiny but rapid expansion or bending.
- This deformation is either amplified or directly transmitted to the device, achieving displacement or vibration.
Voice Coil Actuator (VCA)
A voice-coil actuator generates linear force through the interaction between current in a coil and a permanent magnetic field.It operates similarly to a loudspeaker. It generates straight-line motion or vibration through the interaction between a coil and a permanent magnet. Unlike rotary motors, VCA directly achieves single-axis linear displacement, making it widely used in haptics and precision control.
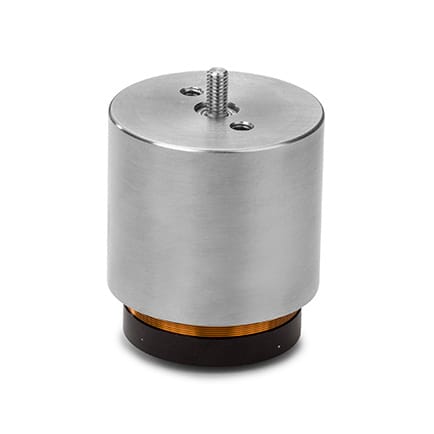
Driving Process:
- When current passes through the coil, a Lorentz Force is generated between the coil and the magnet.
- This force pushes the coil or magnet to move linearly along a single axis.
- Current direction determines the force direction, while current magnitude affects the generated force. Actual displacement and vibration also depend on the suspension, frequency and external load.
For a detailed comparison of ERM, LRA, VCA and piezoelectric technologies, see our Haptic Motors Selection Guide.
Vibrating Electric Motor Types
Vibrating motors can be categorized into four types based on their core drive mechanism: Voice Coil Actuator (VCA), Piezo Actuator, Linear Resonant Actuator (LRA), und Eccentric Rotating Mass Motor (ERM).
They rely on different physics principles to generate periodic vibration. Each offers distinct advantages in response speed, energy efficiency, frequency characteristics, and haptic performance.
The ERM vibrating electric motor, as the most common type, is further subdivided into: brushed, brushless, SMD, coreless/cylindrical, coin/pancake, encapsulated, and sonic vibration motors.
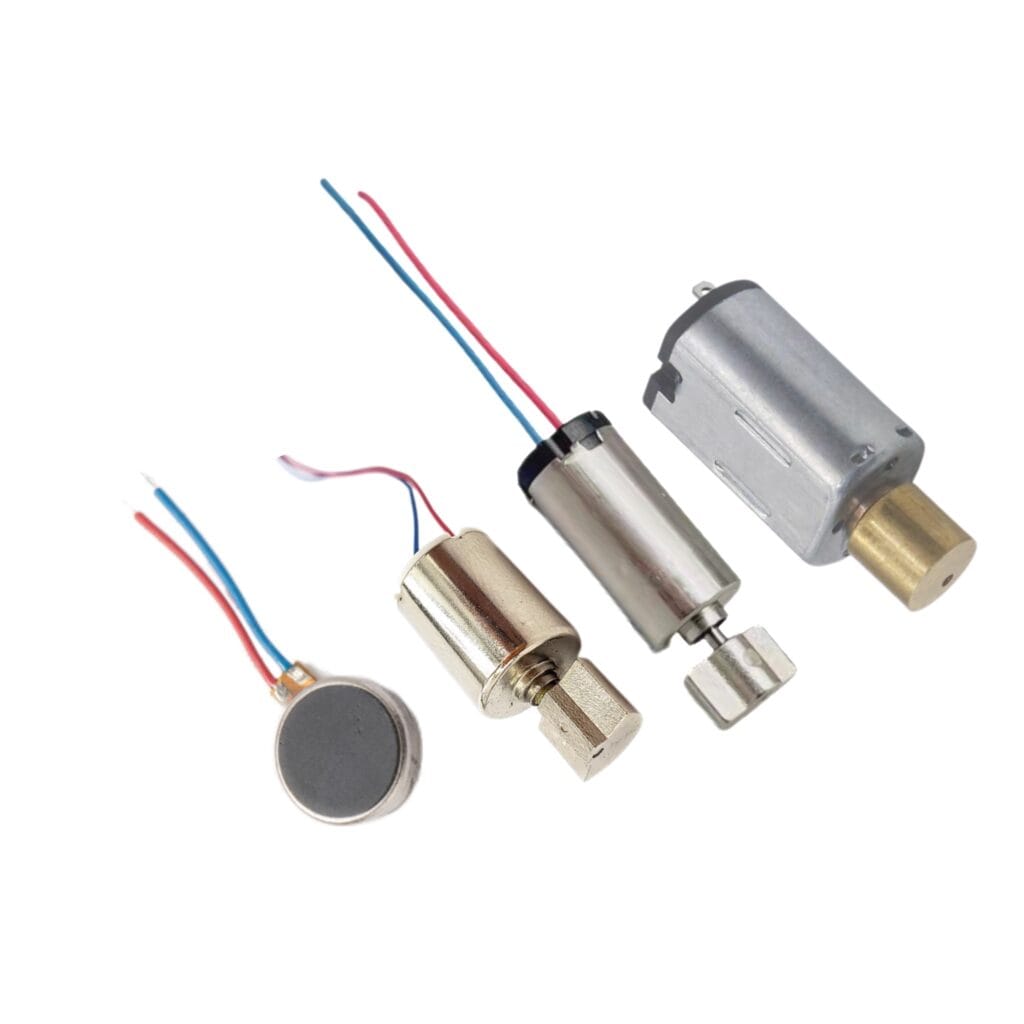
Precision/Controllable Vibrating Electric Motors
These motors are typically used in scenarios requiring high precision, fast response, or specific waveform control. Examples include haptic feedback, optical focusing, and active vibration cancellation.
Voice Coil Actuator (VCA)
Key features: Linear motion, fast response, and force that is approximately proportional to coil current within its operating range. Accurate position, speed or force control normally requires suitable feedback and a controller.
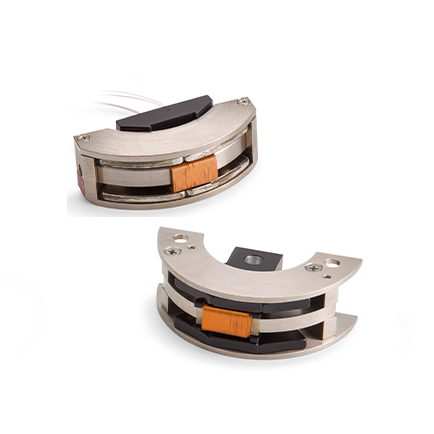
Advantages: Fast response, smooth bidirectional force and no brush or commutator wear.
Disadvantages: Controlled motion may require position or force feedback. Cost and size depend on the required force, stroke and sensor configuration.
Anwendungen: High-end haptics (force feedback wheels, VR controllers), optical positioning, vibration tables, hard disk head drives.
Piezoelectric Actuator
Key features: Small displacement, high stiffness and fast response. Actual resolution depends on the actuator, driver, sensor and mechanical structure.
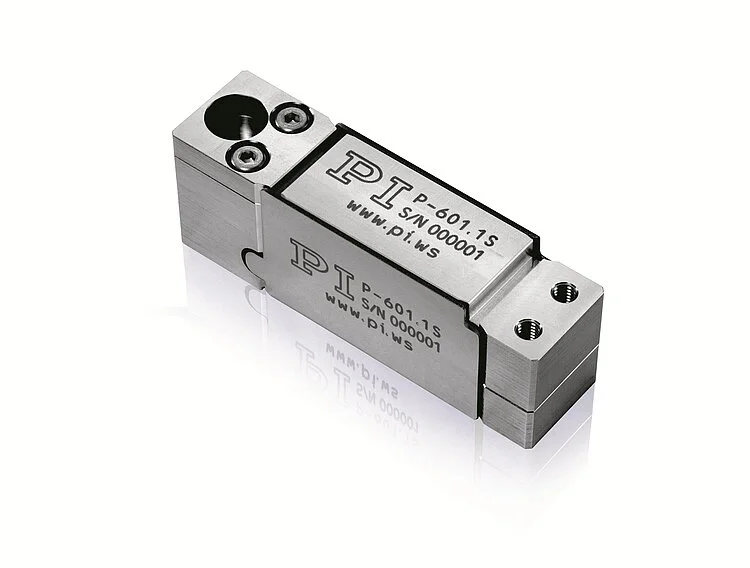
Advantages: Fast response, high force relative to size and no magnetic field required at the actuator.
Disadvantages: Limited stroke, hysteresis and creep. Drive-voltage requirements vary by design and often require specialized electronics.
Anwendungen: Nano-positioning platforms, precision optics adjustment, inkjet printer heads, active vibration control, ultrasonic motors.
Linear Resonant Actuator (LRA)
Key features: Operates within a relatively narrow frequency range and normally produces its strongest response near resonance.
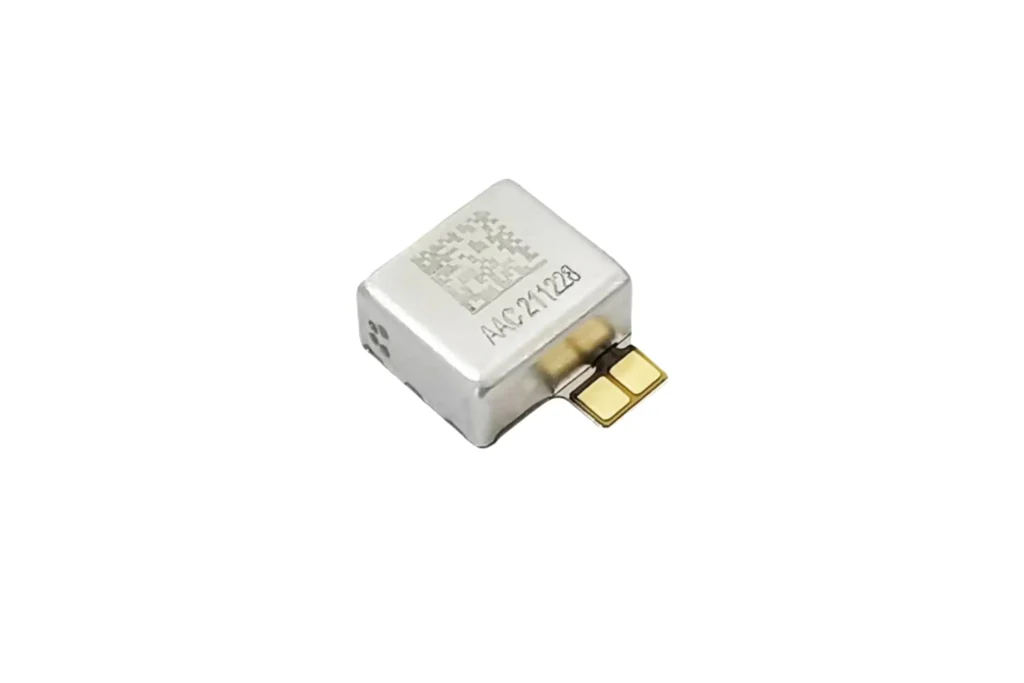
Advantages: Fast start and stop with a suitable driver, efficient operation near resonance and well-defined single-axis vibration.
Disadvantages: The resonant frequency is determined by the mechanical structure and may shift with mounting, manufacturing tolerance and temperature. A compatible AC drive waveform or dedicated driver is required.
Anwendungen: Smartphones, smartwatches for haptic feedback. Provides finer vibration than ERM.
Eccentric Rotating Mass Vibrating Electric Motor (ERM)
The ERM motor is the most classic and widely applied type.All variants are based on this mechanism, differing only in motor form, structural design, and packaging.
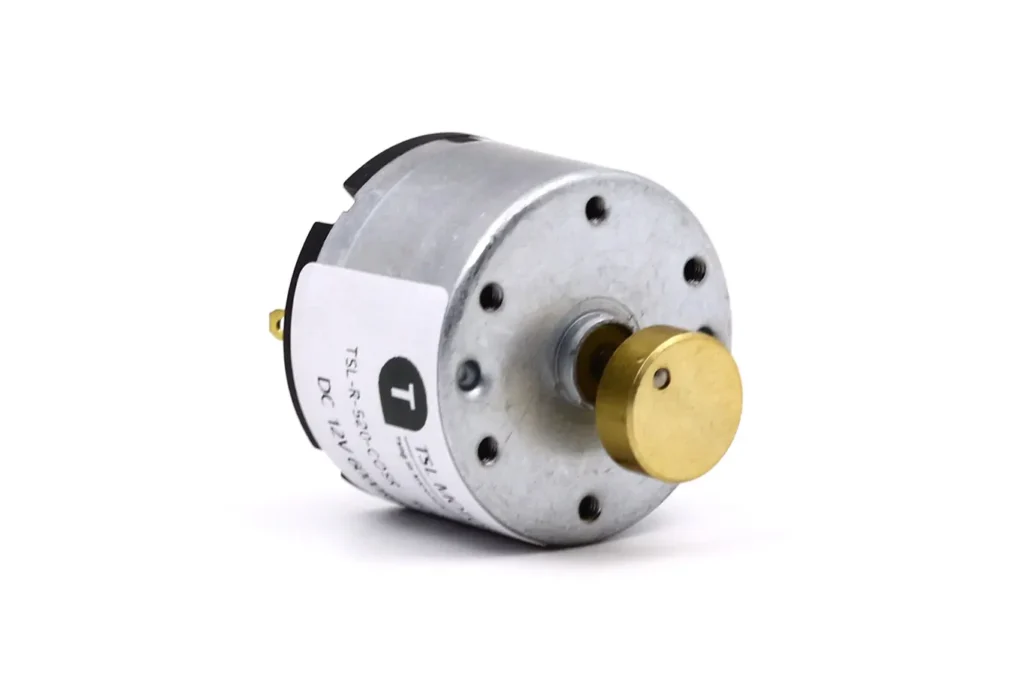
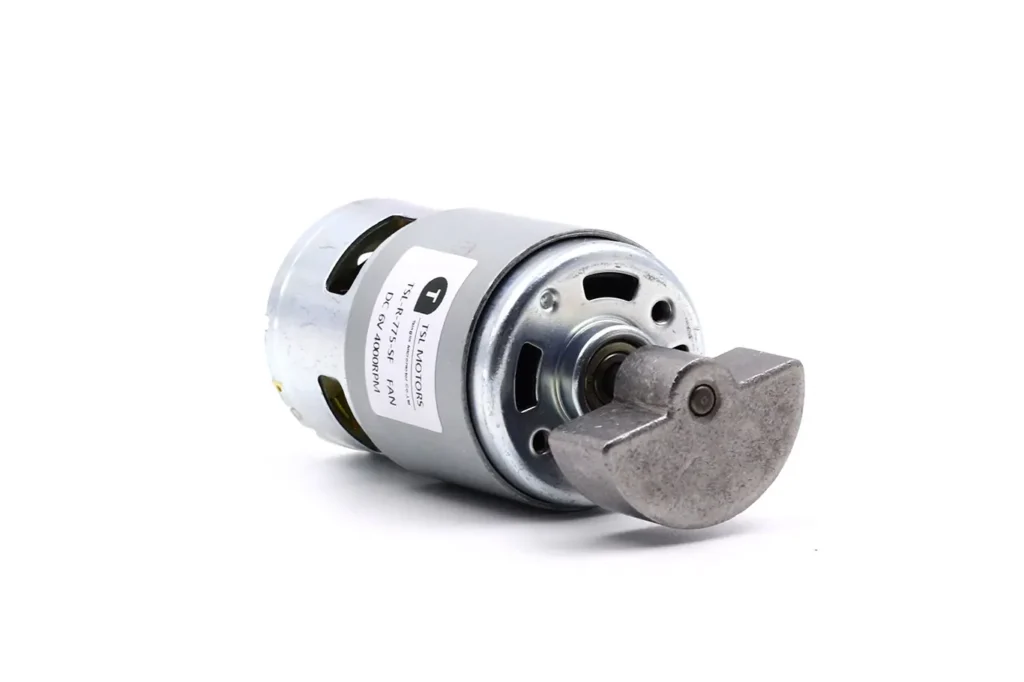
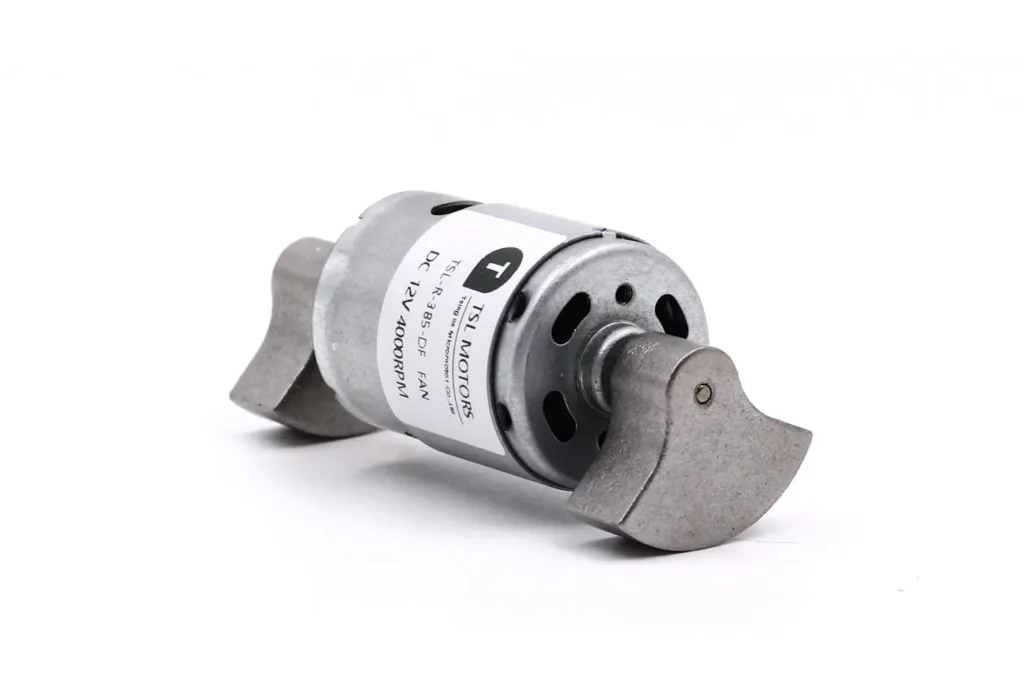
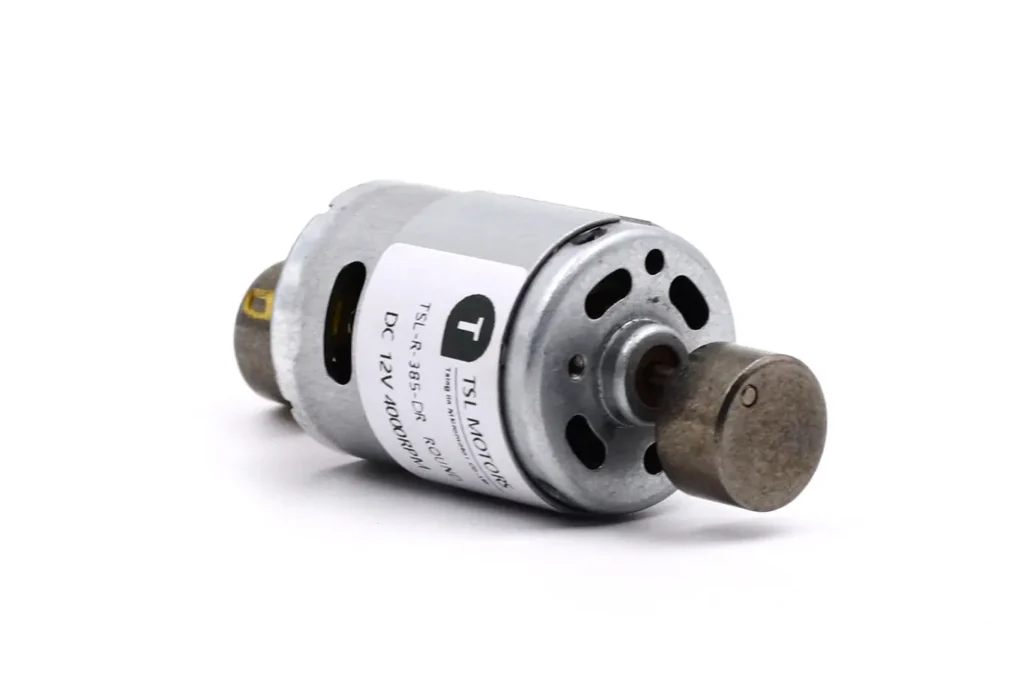
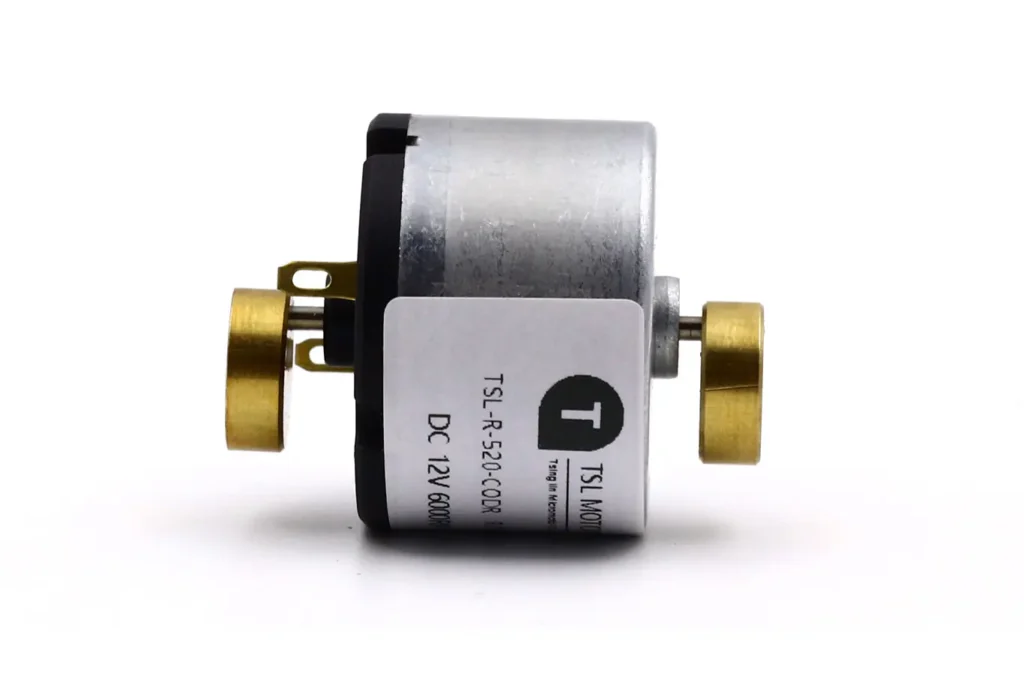
Brushed ERM Motor
Features: Simple construction and straightforward DC operation.
Advantages: Generally lower cost and easy to integrate. Vibration intensity can be adjusted by changing the applied voltage or using PWM within the motor’s rated limits.
Disadvantages: Brushes and commutator contacts wear during operation and can generate electrical noise. Service life depends on speed, voltage, duty cycle, temperature and starting frequency.e.
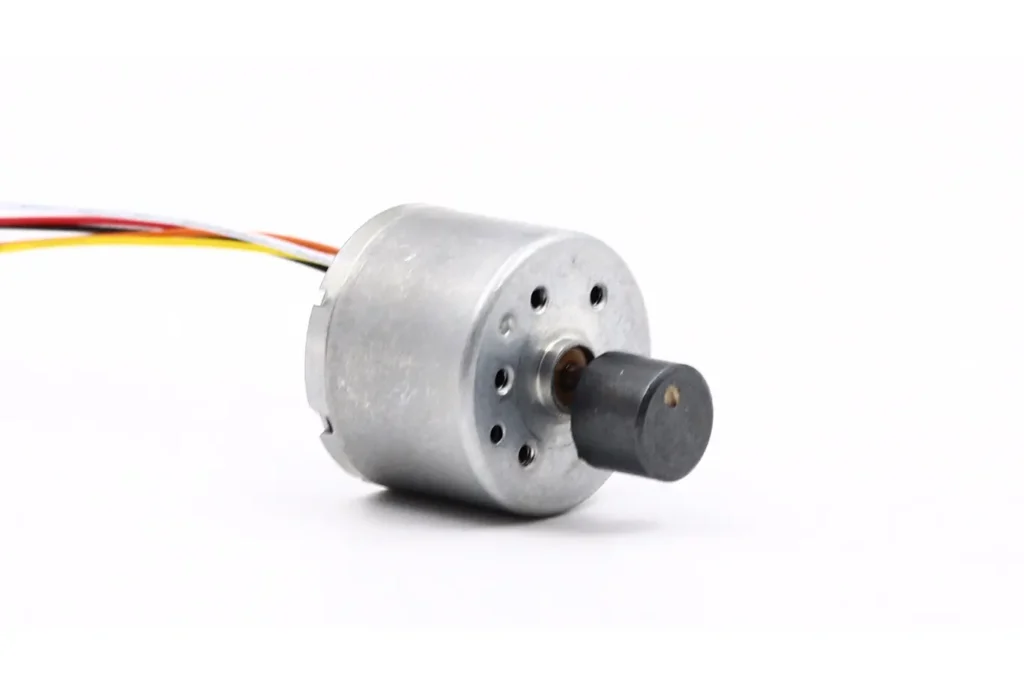
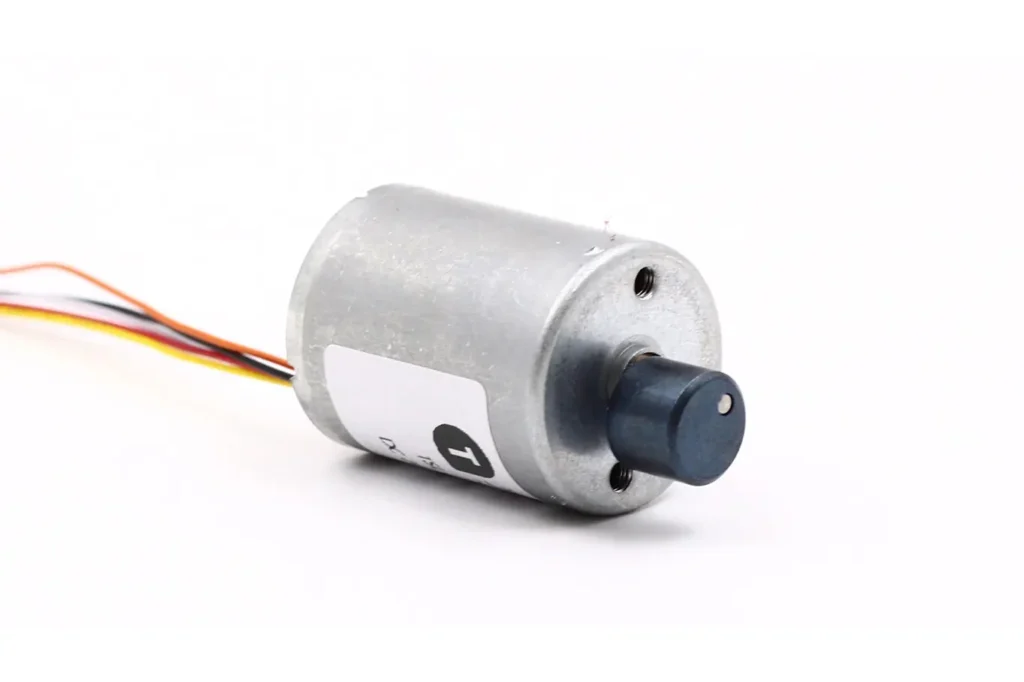
Brushless ERM Motor
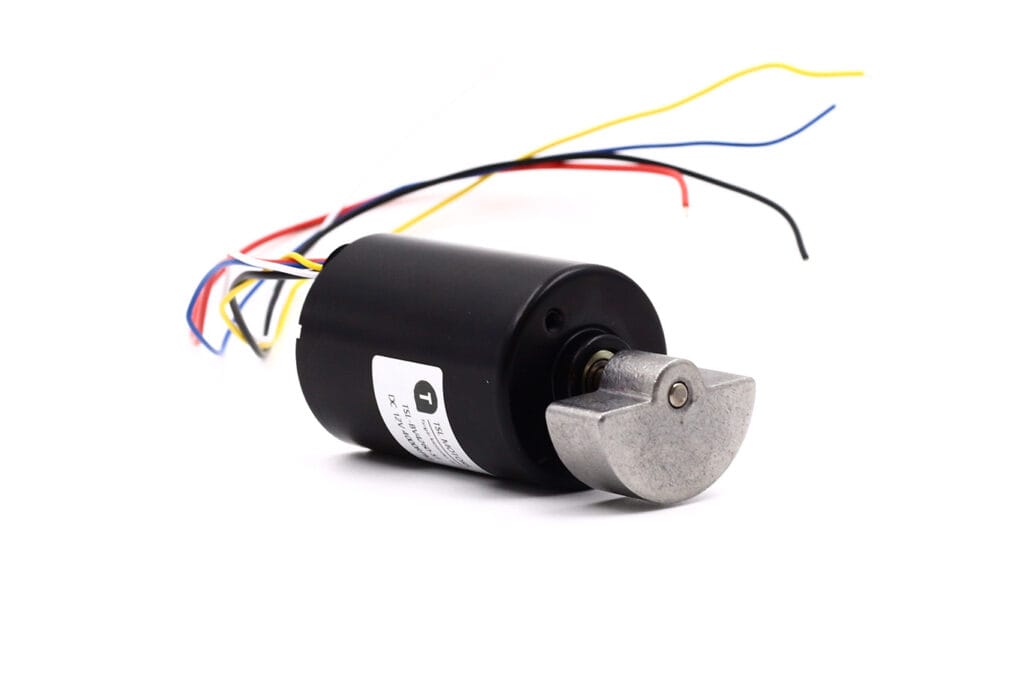
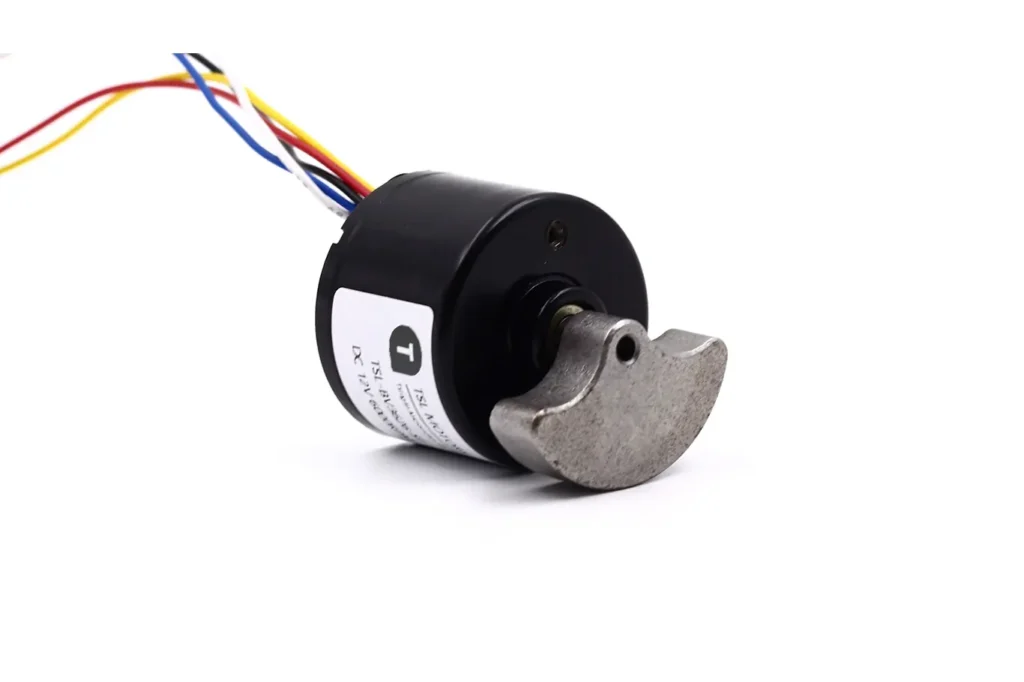
Features: Electronic commutation eliminates brush and commutator wear, making brushless ERM motors suitable for applications with longer operating time or frequent duty cycles. Actual efficiency, noise and service life still depend on the motor design, bearings, driver and operating conditions.
Disadvantages: Requires an electronic driver and normally has a higher system cost than a comparable brushed ERM motor.
SMD ERM Motor
Features: Designed for surface mounting and automated PCB assembly. The permitted reflow profile, pad layout and mounting orientation must follow the motor datasheet.

Anwendungen: Mass production consumer electronics, such as TWS earbuds and ultra-thin smartphones.
Coreless / Cylindrical ERM Motor
Working principle: Rotor uses ironless “coreless cup” coil winding.
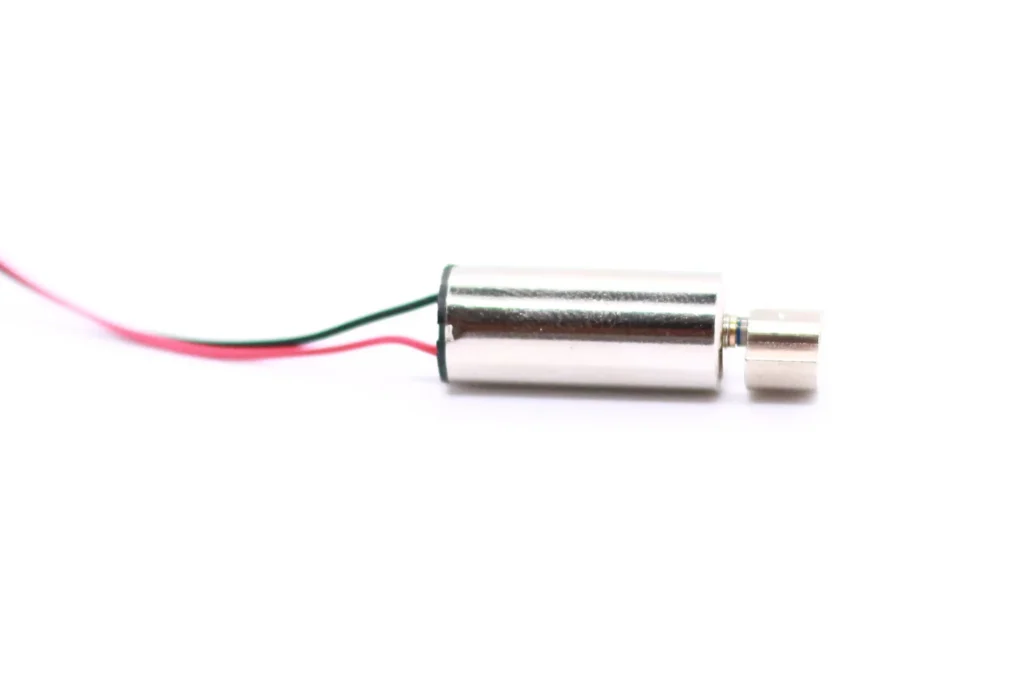
Features: The low-inertia coreless rotor can improve acceleration and dynamic response. Actual start and stop performance also depends on the eccentric mass, applied voltage, drive method and mounting structure.
Anwendungen: Devices requiring fast response, such as high-end game controllers and medical instruments (e.g., insulin pumps).
ekapselte Vibrationsmotoren
Features: The ERM motor is enclosed in a molded resin, plastic or metal housing, depending on the product design.
Advantages: Encapsulation can improve protection against moisture, dust, impact and accidental electrical contact. The actual protection level must be confirmed through the product’s IP rating and environmental test conditions.
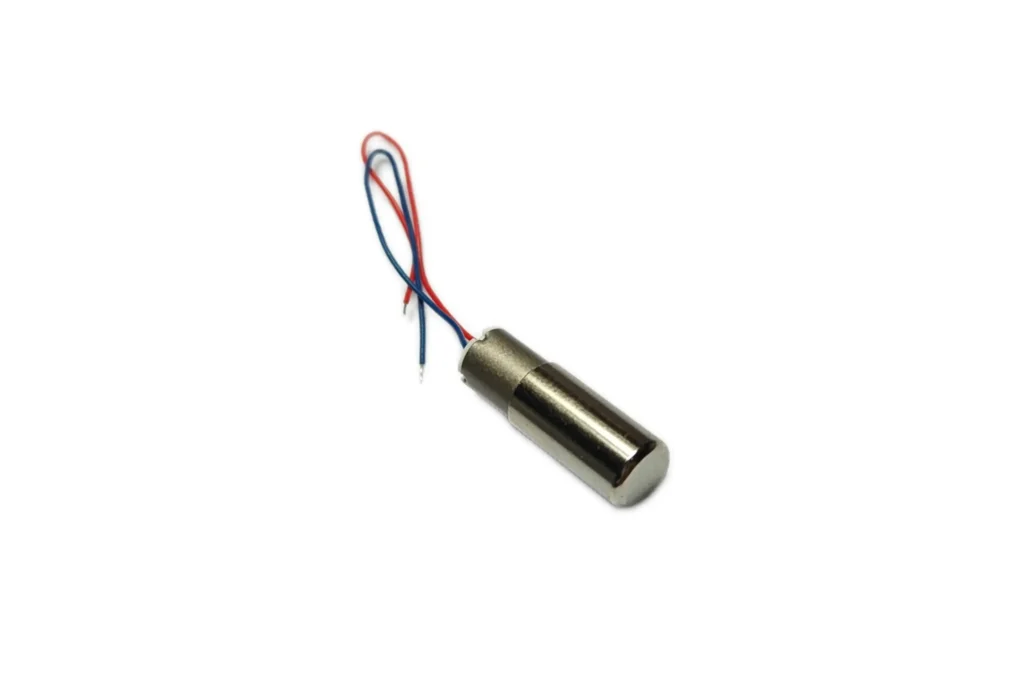
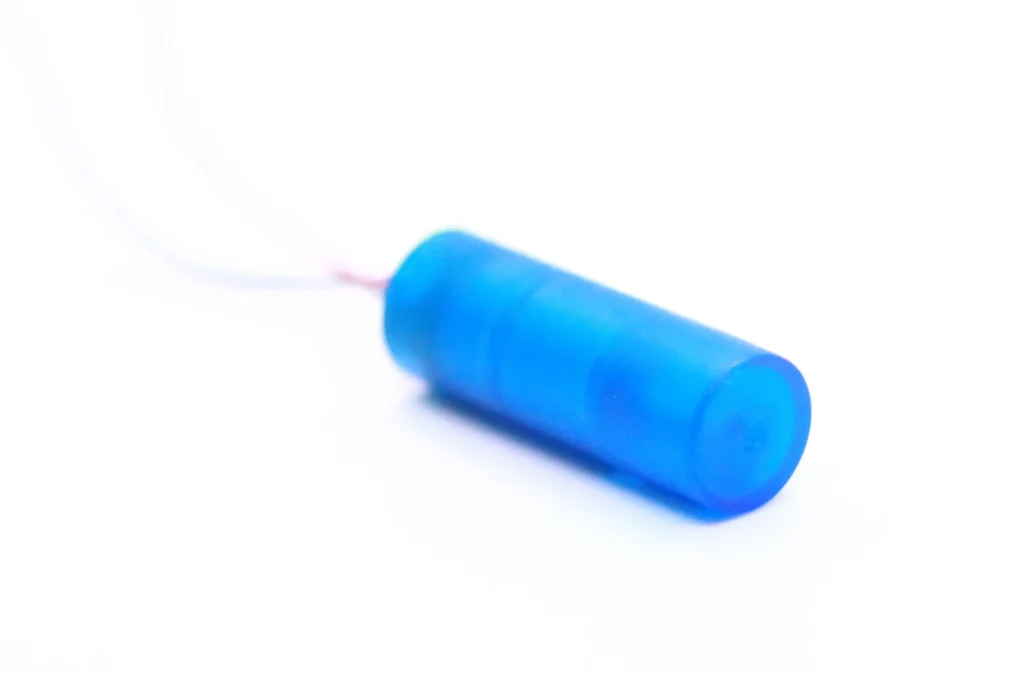

Anwendungen: Outdoor devices, wearables, products exposed to moisture or harsh environments.
Coin / Pancake Vibration Motor
Structure: Flat design. Eccentric weight rotates in a plane. Diameter larger than thickness.
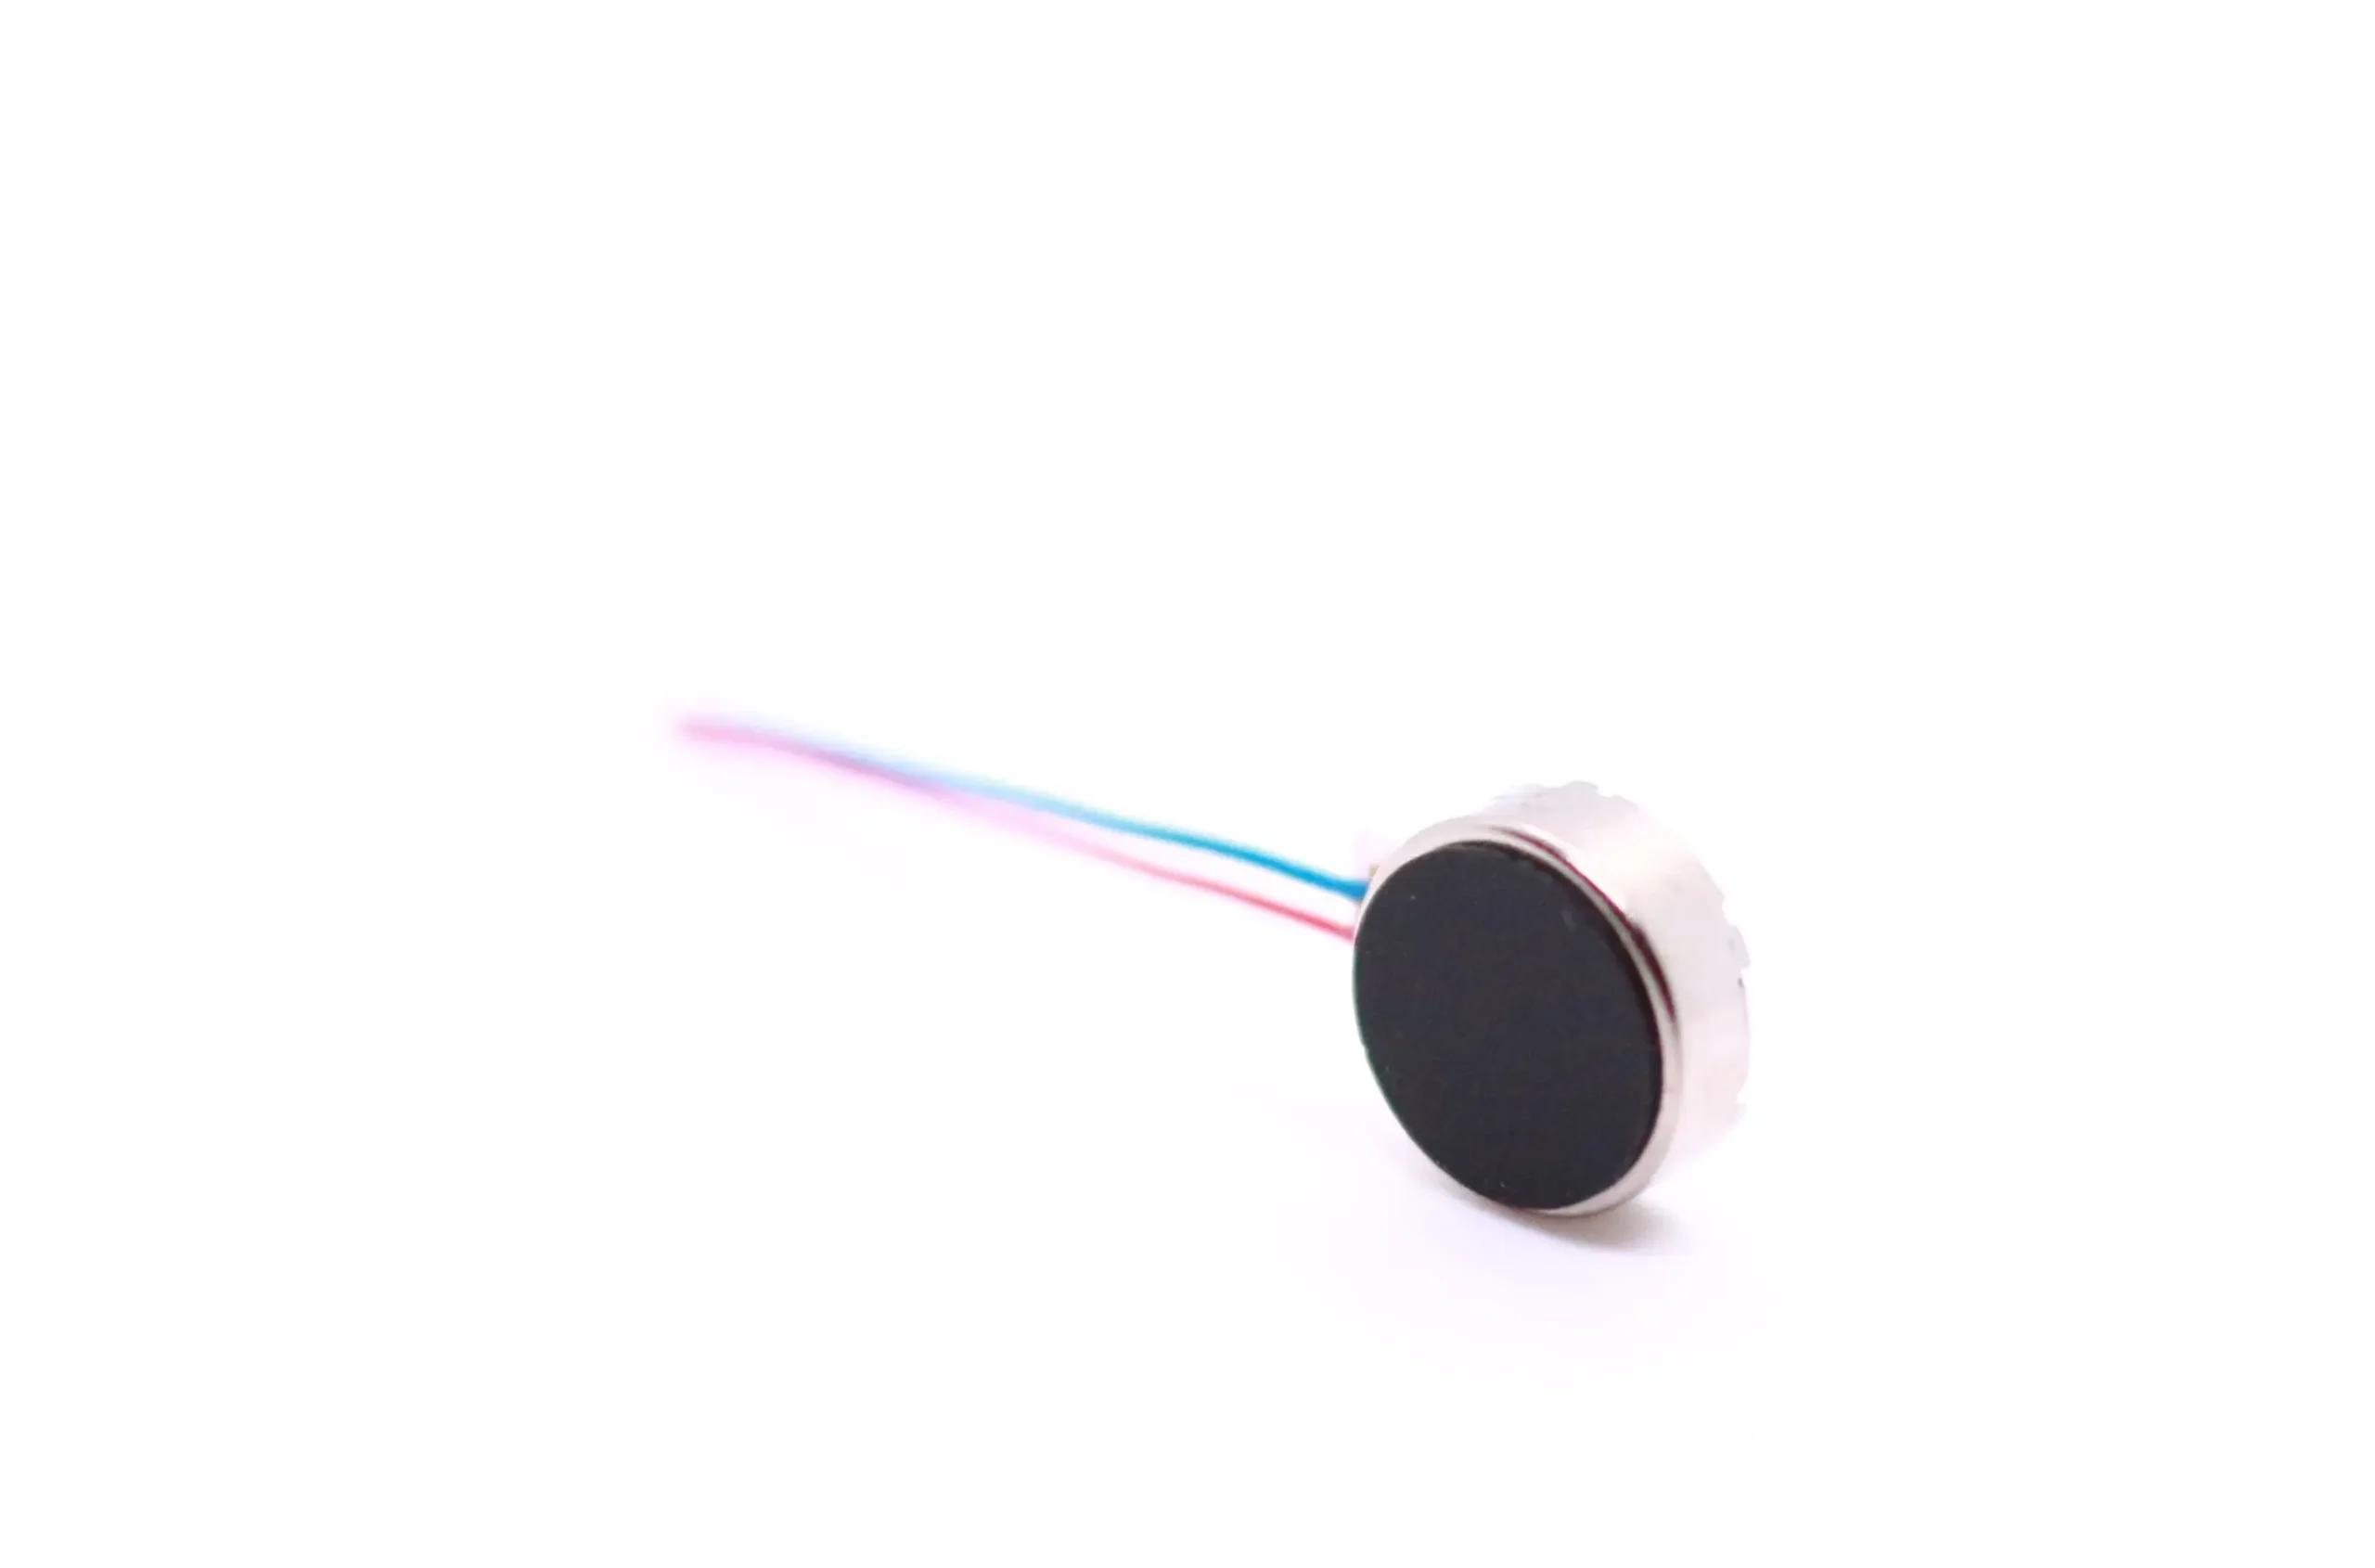
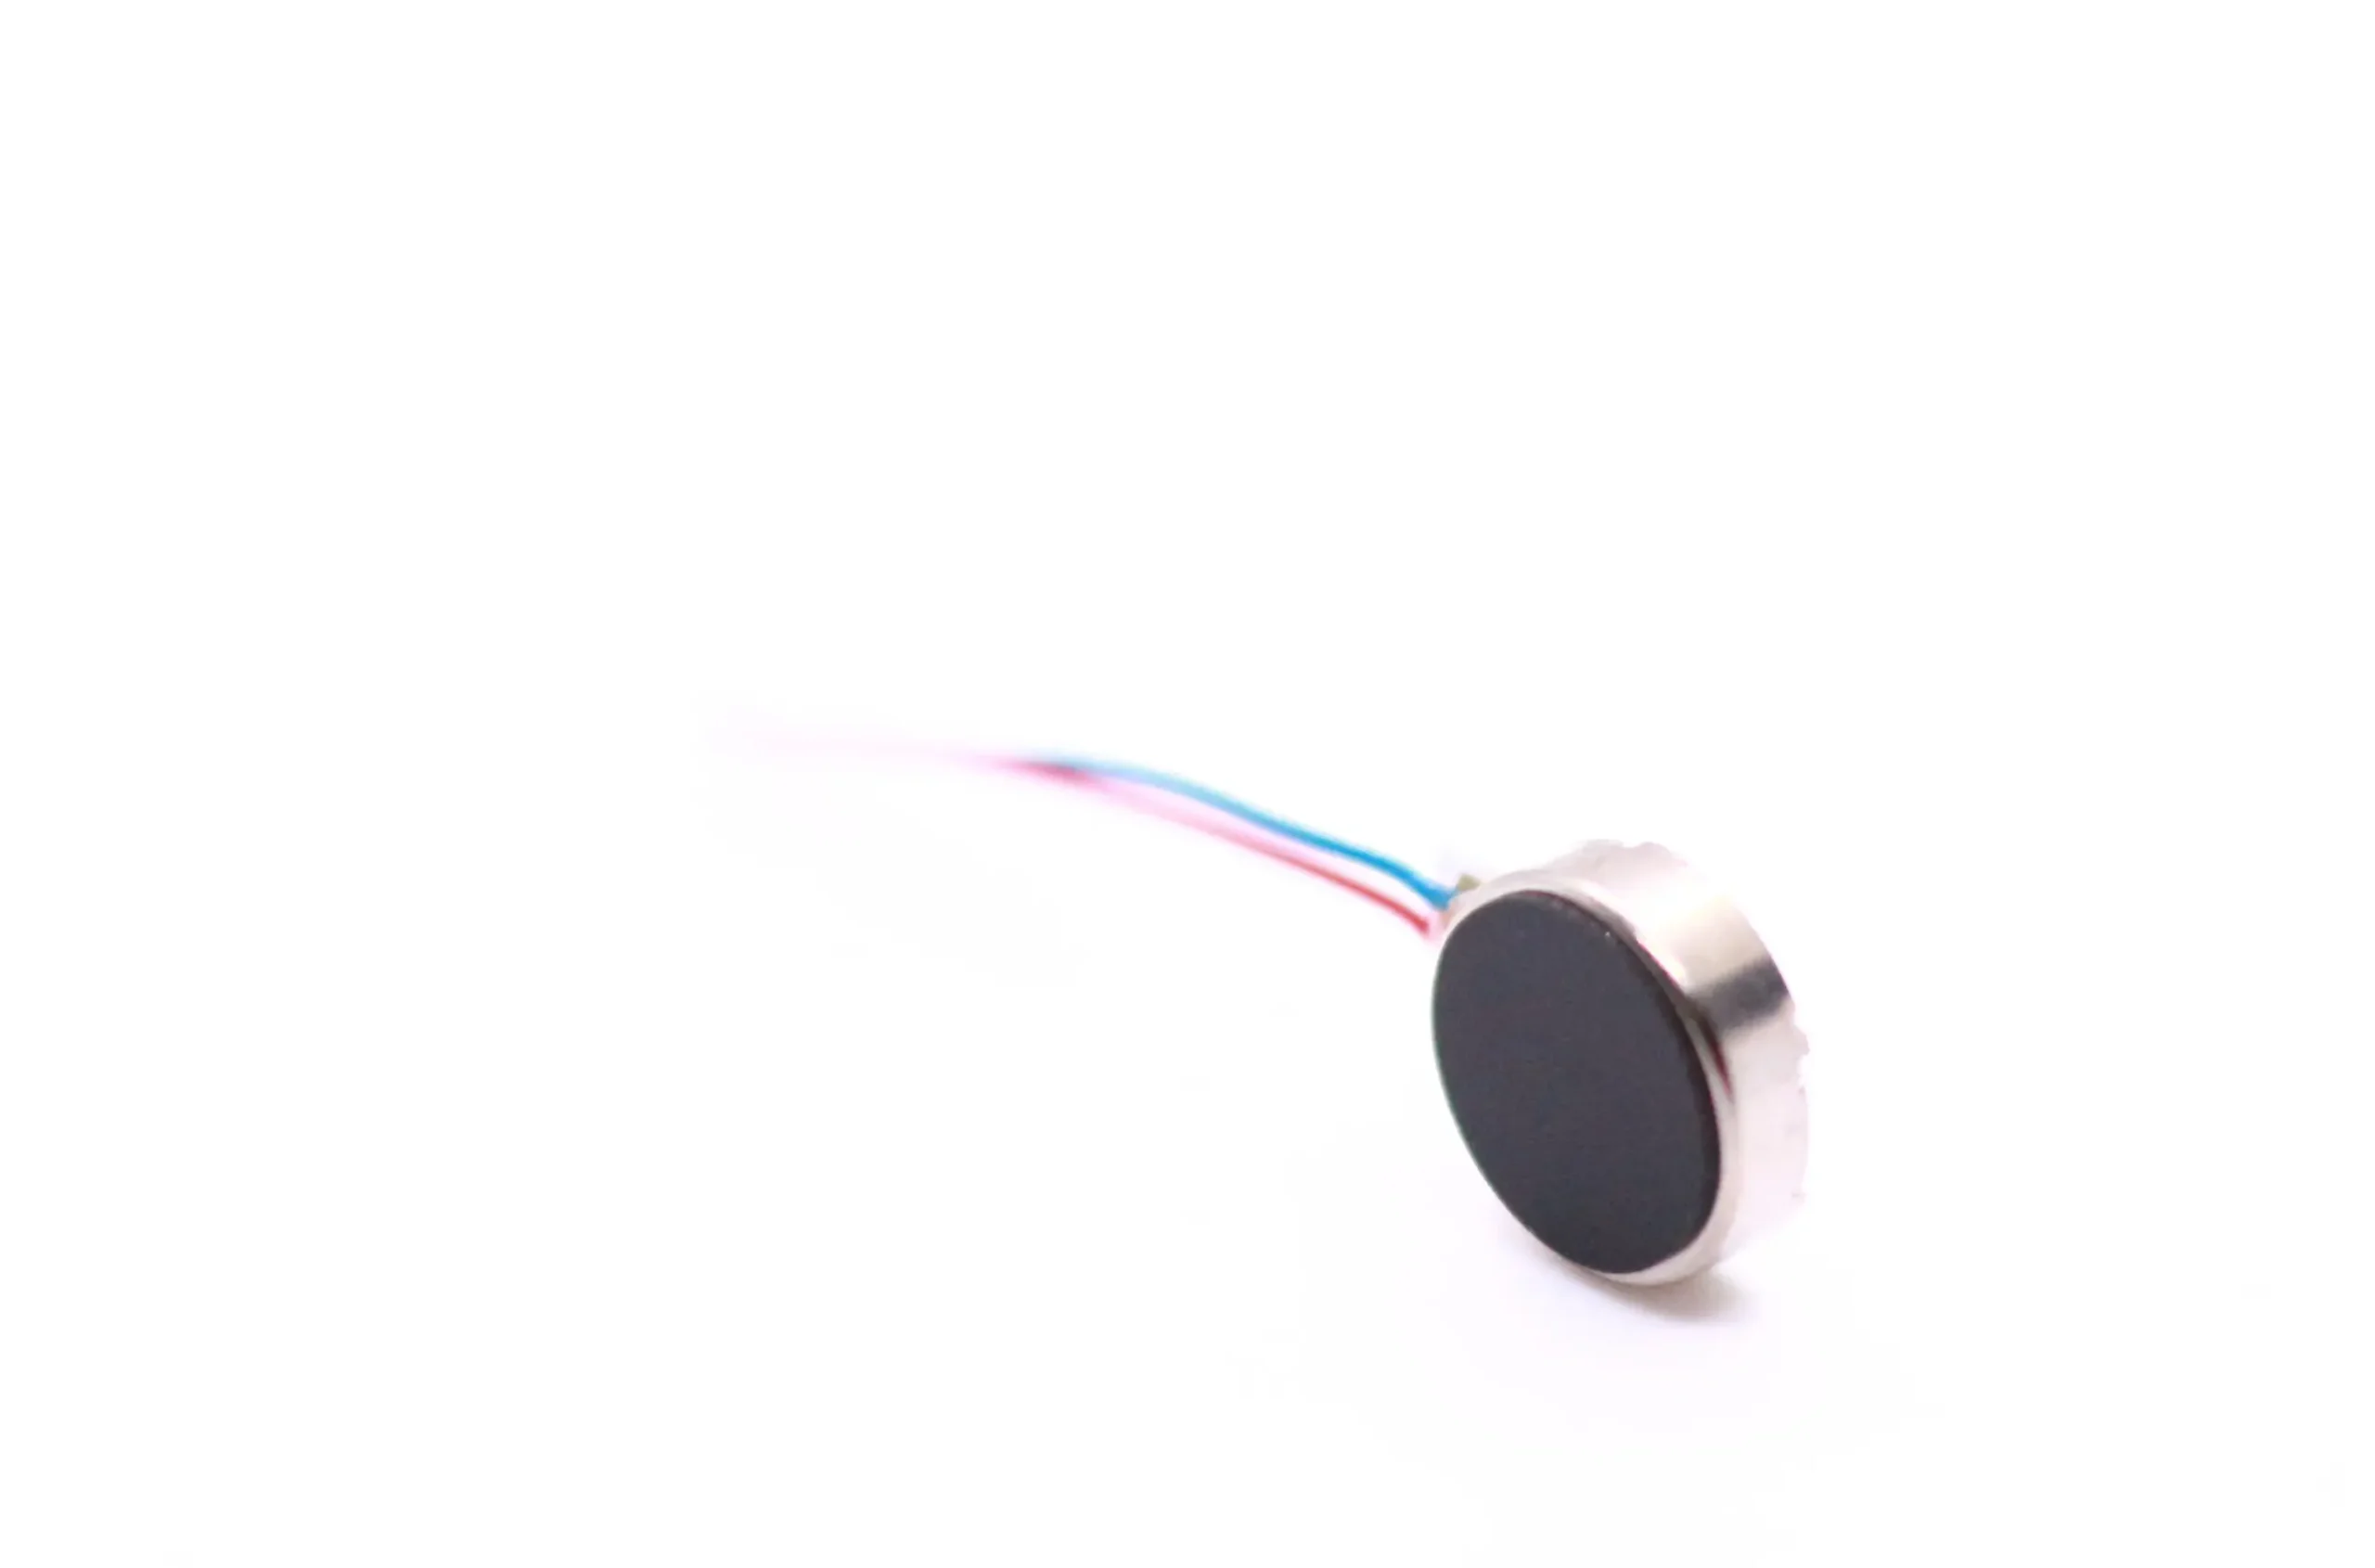
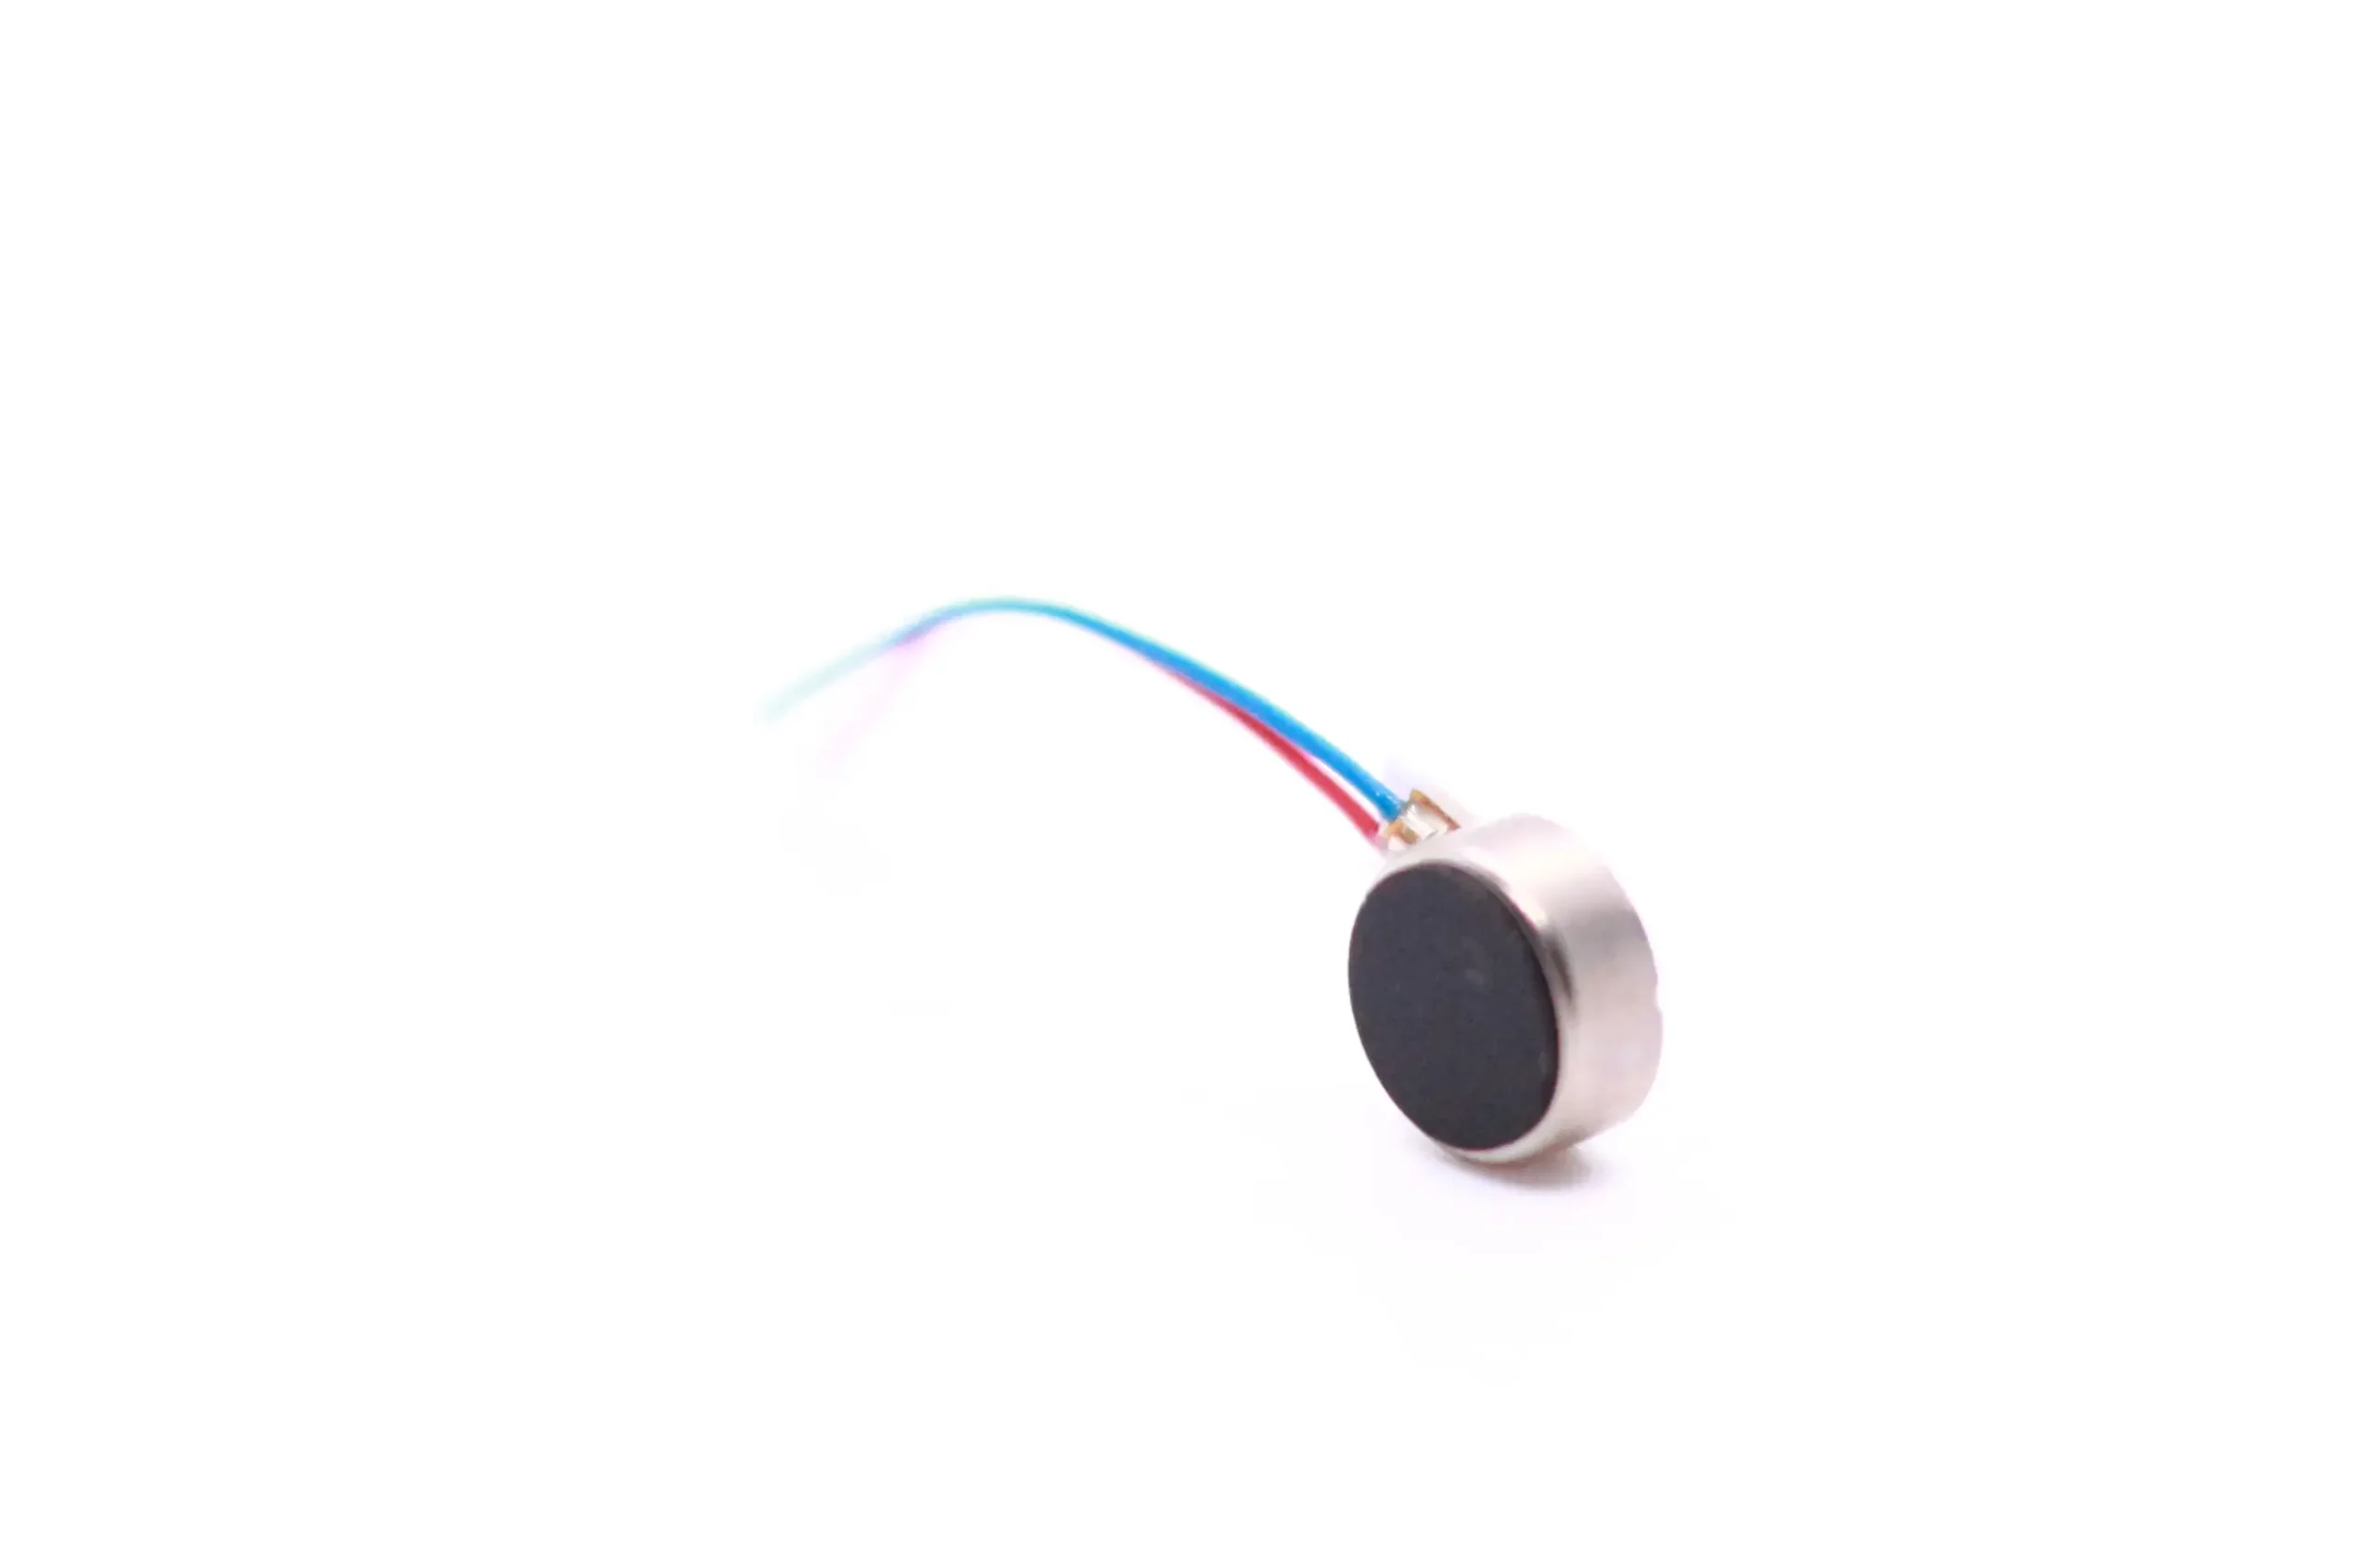
Advantages: Saves thickness space. Ideal for ultra-thin devices.
Disadvantages: The thin package limits the available space for the motor and eccentric mass. Actual vibration output should be compared using acceleration or vibration-force data under the same voltage, mounting and load conditions—not by package diameter alone.
Anwendungen: Smartphones, smart cards, ultra-thin wearables.
Schall-Vibrationsmotoren
Working principle: “Sonic vibration motor” is a broad commercial term that can describe different structures, including high-speed rotary motors and resonant oscillating actuators. The actual operating mechanism should therefore be confirmed from the product datasheet.
For a rotary design, the fundamental vibration frequency is related to rotational speed:
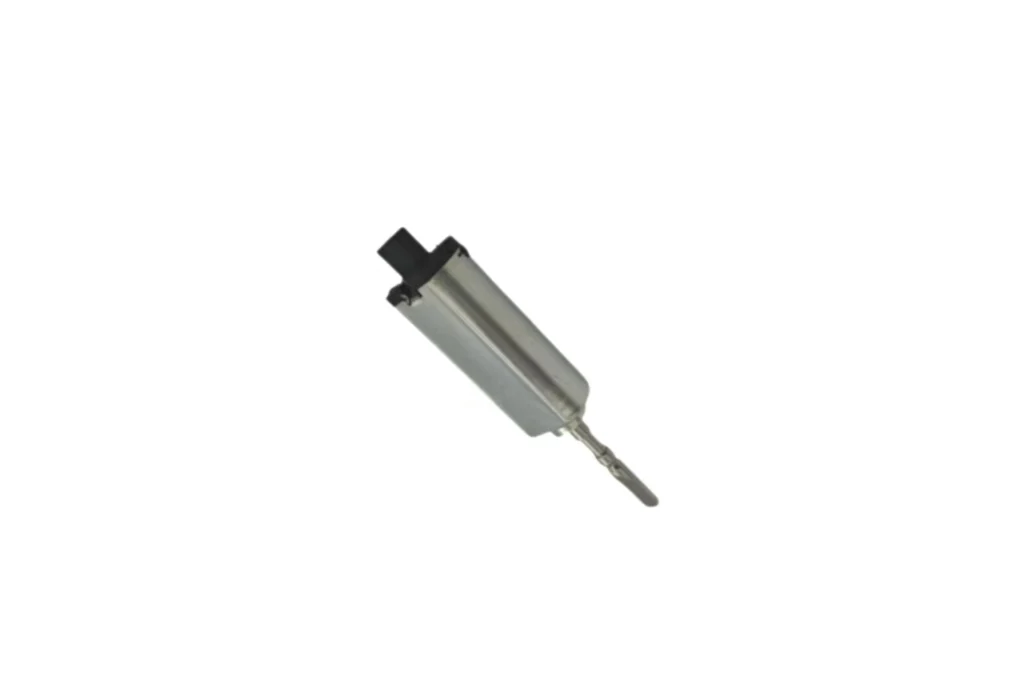
Vibration frequency (Hz) = Motor speed (rpm) ÷ 60
For a resonant oscillating design, the operating frequency is determined mainly by the mechanical resonant system and drive frequency rather than by shaft speed.
Advantages: Can provide high-frequency vibration for cleaning, brushing or compact massage functions, depending on the actuator structure.
Limitations: Frequency, displacement, noise, heat and service life vary significantly between different sonic motor designs.
Anwendungen: Electric toothbrushes, cleaning devices and compact health or beauty equipment after verification at the required frequency and load.
Benefits of Vibrating Electric Motors
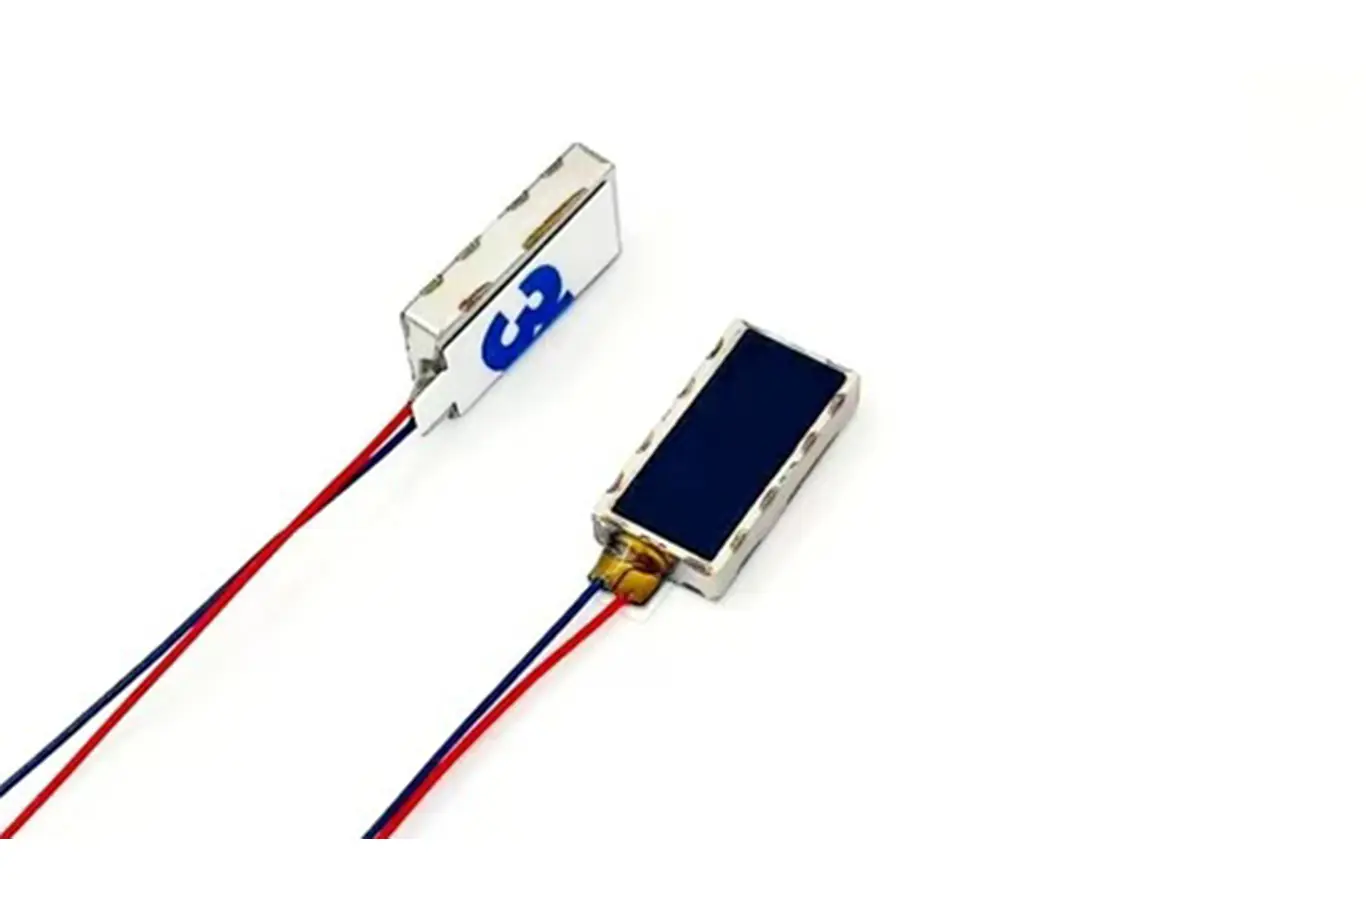
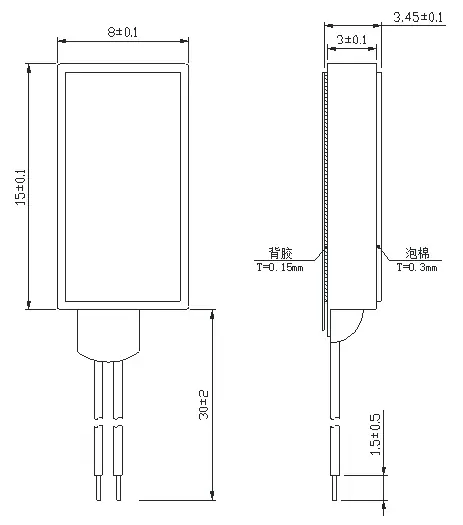
Small size + strong force
Vibration motors are available in compact packages for space-constrained products. Actual output depends on motor size, eccentric mass, speed and installation—not size alone.
Low cost
Brushed ERM motors are often economical for simple vibration alerts and volume production. Total system cost should also include the driver, mounting components, assembly and validation.
Simple driving requirements
Many brushed ERM motors can be controlled with a basic DC switching circuit or PWM. BLDC vibration motors, LRAs and other actuators require compatible drivers, so the drive method must be confirmed for each motor type.
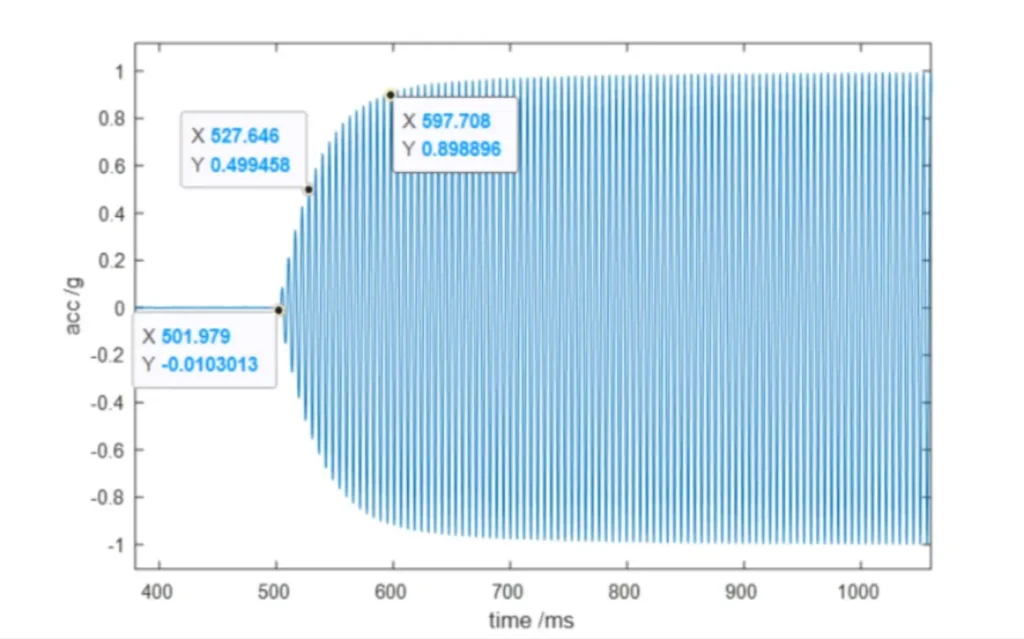
Fast response speed
LRA and low-inertia ERM designs can provide relatively fast response. Actual startup, stopping and residual vibration depend on the actuator, driver, braking method and installed product structure.
High reliability
Brushless construction removes brush and commutator wear, while encapsulation can improve environmental protection. Bearings, springs, electrical contacts, temperature and duty cycle may still limit service life.
Low power consumption
Small vibration motors can support battery-powered products when correctly matched to the required output and duty cycle. Compare peak current, average power and energy per vibration event rather than assuming one motor type always consumes less power.
Applications of Vibrating Electric Motors
Vibrating motors are used in a vast range of applications. Different sectors have varied requirements for vibration intensity, frequency, lifespan, and noise. Here is an in-depth look at four major application categories:
Consumer Electronics & Wearables
Typical devices include smartwatches, wearable alerts, game controllers and portable electronics.
Design considerations:
- Available diameter and thickness;
- Required alert or tactile response;
- Battery capacity and peak current;
- Mounting direction and acoustic noise.
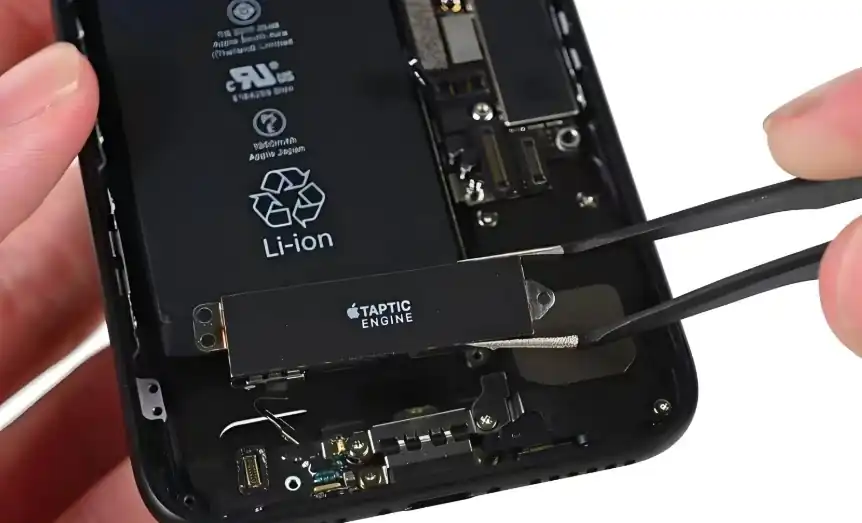
As LRA manufacturing and driver technology have matured, linear resonant actuators have become a mainstream haptic solution for smartphones and many consumer electronic devices. Their fast start-stop response and well-defined vibration are suitable for virtual buttons and short tactile effects.
Coin ERM motors remain practical for cost-sensitive products that require simple vibration alerts and straightforward DC control.
Health & Beauty Devices
Typical Devices: Facial massagers, handheld therapy devices, muscle stimulators, portable massage guns.
Design Considerations:
- Vibration Intensity: Directly impacts user experience. Massage guns need strong vibration; facial beauty devices require soft, high-frequency vibration.
- Noise Control: Beauty and medical equipment must be quiet for user comfort.
- Reliability: Devices may run for long periods. Long-lifespan brushless motors or Sonic Motors are required.
Case Studies:
- Sonic facial brush uses a Sonic Motor for high-frequency, delicate vibration.
- Portable massage guns use high-power cylindrical ERM Motors for strong muscle stimulation.
Industrial Applications
Typical Devices: Material feeders, concrete vibrators, industrial shakers, small vibration platforms, precision dosing systems.
Design Considerations:
- High Strength & Long Life: Industrial equipment often runs continuously. Brushless ERM or high-power motors are essential.
- Environmental Adaptability: Equipment may operate in dusty, damp, or high-temperature environments. Encapsulated motors are required.
- Power/Size Matching: Feeders need high-power motors; precision dosing systems require small but stable vibration sources.
Case Studies:
- Concrete vibrating rods use high-power ERM Motors on construction sites.
- Precision feeders in the pharmaceutical industry use Encapsulated ERM Motors to ensure reliability and hygiene.
Automotive Applications
Typical Devices: Feedback buttons, haptic dashboards, seat vibration alerts.
Design Considerations:
- Safety: Haptic feedback must be clear and reliable, used for driver assistance and warnings.
- Environmental Resilience: Car interior temperatures fluctuate widely. Motors need high-temperature resistance and anti-vibration performance.
- Low Noise & Fast Response: Driving environments require quiet operation. Vibration must start and stop quickly.
Case Studies:
- High-end car seat safety alert systems use LRA Motors for precise haptic warnings.
- Haptic dashboard buttons use Coin Motors to simulate the feel of physical button clicks.
Key Specifications and Selection Guidelines for Vibrating Electric Motors
In real-world projects, motor selection involves far more than simply asking “Can it vibrate?”. Engineers must evaluate electrical parameters, mechanical structure, lifespan, and application environment. The following specifications and practical guidelines form the basis of reliable design decisions:
Rated Voltage / Operating Voltage
Common vibration-motor voltages include 3V, 3.7V, 5V and 12V, but the permitted operating range and starting voltage must be checked for the specific model.
For the same ERM motor, increasing voltage normally increases speed and vibration output, but it may also increase current, temperature, brush wear and bearing load. A motor with a higher rated voltage is not automatically more powerful than a lower-voltage model. BLDC motors and LRAs must also be matched to a compatible driver.
Vibration Force / Acceleration
Vibration force and acceleration are related but are not the same parameter. Force is normally expressed in newtons, while acceleration is expressed in m/s² or multiples of gravitational acceleration, written as g.
The measured acceleration depends on both the motor output and the mass, stiffness and resonance of the test fixture. Values from different suppliers should only be compared when the test and mounting conditions are similar.
Speed (RPM)
For an ERM motor with one rotating eccentric mass, its fundamental vibration frequency is related to motor speed:
Vibration frequency (Hz) = Motor speed (rpm) ÷ 60
Increasing speed also increases centrifugal force, but noise, current, wear and temperature may rise. The final vibration measured in the product can also increase or decrease near structural resonance.
Current and Power Consumption
Check rated current, starting current and peak driver current separately. The driver and battery must tolerate the starting current without causing excessive voltage drop.
Electrical input power can be estimated as:
Input power ≈ Voltage × Current
For intermittent haptic feedback, energy consumed per vibration event may be more useful than continuous power alone. Both peak current and average energy consumption should be verified in the intended operating cycle.
Motor Size and Mounting Method
Motor diameter and thickness determine whether the actuator fits, but mounting determines how effectively vibration enters the product.
Coin motors commonly use adhesive mounting, cylindrical motors may use clips or molded holders, and SMD motors mount directly to a PCB. The mounting surface must be clean, sufficiently stiff and able to withstand repeated vibration. Cable routing, connector position and vibration direction should also be checked before finalizing the mechanical design.
Lifespan and Reliability
Service life should be evaluated under the specified voltage, duty cycle, temperature, mounting and vibration load. Brushed motors are affected by brush and commutator wear, while brushless motors, LRAs and other actuators may still be limited by bearings, springs, solder joints, adhesives or electronic components.
Life values from different suppliers are only comparable when their test conditions and failure criteria are similar.
Noise and Vibration Smoothness
Vibration motors produce both airborne noise and structure-borne noise. A motor that sounds quiet when tested loosely may become louder after it is attached to a housing, panel or PCB.
Noise and vibration smoothness should therefore be evaluated in the assembled product at the intended voltage, duty cycle and mounting condition.
Practical Selection Guidelines
A practical selection process is:
- Define whether the product needs a simple alert, a controlled tactile effect or continuous process vibration.
- Confirm the available space, voltage, driver, mounting method and vibration direction.
- Compare acceleration, frequency, current and response data under similar test conditions.
- Check starting current, duty cycle, temperature, noise and required service life.
- Test candidate motors in the actual product before approving the final specification.
TSL Motor can adjust parameters such as rated voltage, eccentric mass, lead-wire length, connector and mounting accessories. Any customized configuration should be confirmed through samples and testing in the customer’s assembled product.
Fazit
Vibrating electric motor performance depends on the interaction between the actuator, driver, mounting structure and receiving product. Selection should begin with the required acceleration, frequency, response time, duty cycle, available space, noise and service-life conditions. Datasheet values should only be compared when their measurement and mounting conditions are similar.
TSL Motor supplies ERM, LRA, brushless, coin, cylindrical and encapsulated vibration solutions, with options for voltage, eccentric mass, lead wires, connectors and mounting accessories. Final performance should be confirmed through sample testing in the assembled product before production specifications are approved.
✅ If you are looking for reliable, efficient, and customizable vibrating motors and haptic feedback solutions, TSL MOTOR is your trustworthy one-stop partner.
FAQ
Q1:Why Does the Same Vibration Motor Feel Weaker After Installation?
The motor may produce the same rotating force, but the product’s mass, mounting stiffness, housing material and structural resonance change the measured acceleration. A loose mount may absorb motion, while a rigid panel may transmit or amplify vibration at particular frequencies. Test the motor in the final assembly rather than judging it by hand.
Q2:Can I Increase the Voltage to Get Stronger Vibration?
For the same brushed ERM motor, increasing voltage normally raises speed and centrifugal force. However, exceeding the specified operating range can increase current, temperature, brush wear and bearing stress. Use the rated operating-voltage range and confirm vibration, current and temperature under the intended duty cycle.
Q3:Why Does an ERM Vibration Motor Fail to Start at Low Voltage?
The available voltage may be below the motor’s specified starting voltage, or the power supply and driver may not provide sufficient starting current. Cable voltage drop, low battery charge, mechanical interference or an unsuitable PWM setting can also prevent startup. Measure the voltage directly at the motor terminals during starting.
Q4:Can PWM Control ERM Vibration Strength?
Yes. PWM changes the motor’s effective voltage and therefore its speed and vibration output. However, ERM frequency and centrifugal force change together, so they cannot be controlled independently. The PWM frequency, duty cycle and driver current rating must remain compatible with the motor and application.
How Should Two Vibration Motors Be Compared?
Test both motors on the same fixture or in the same product structure. Use the same voltage, mounting, load and measurement position, then record startup behavior, steady-state acceleration, frequency, current, noise and temperature. Datasheet values measured under different fixture conditions may not be directly comparable.
Vibrationsmotoren
TSL MOTORS designs and manufactures a wide range of high-quality, and cost-effective vibration motors. If you request high-quality micro vibration motors, this is the right place, the quality is guaranteed, and we can provide specifications, datasheets, test reports, performance, and related certifications. Various connection interfaces to choose from. All types of vibration motors can be highly customized for applications. Please contact us freely for samples and detailed quotations.