Published: DECEMBER 14, 2025
Updated:SEPTEMBER 22, 2026
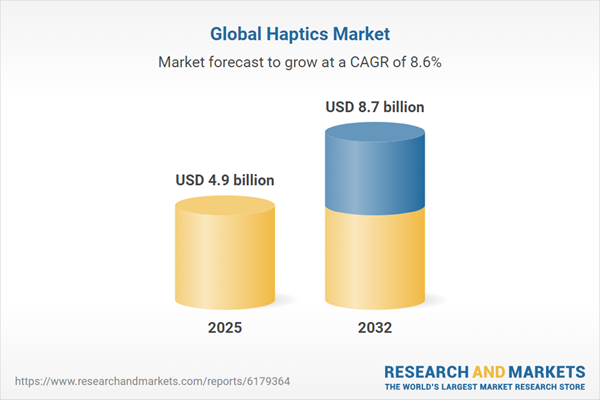
The global haptic feedback market is rapidly growing. It is projected to expand from approximately $4.9 billion in 2025 to nearly $8.7 billion by 2032. This represents a Compound Annual Growth Rate (CAGR) of about 8.6%.
Among various haptic actuators, the LRA (Linear Resonant Actuator) is dominant. It holds about a 45% market share. LRAs are widely used in smartphones, wearables, and high-end electronics. They are a mainstream choice due to their high efficiency and fast response.
We are TSL MOTOR, a dedicated LRA motor manufacturer. We provide high-performance, reliable haptic solutions globally.
This article explores four key areas. It covers the working principle, core advantages, typical applications, and selection essentials. This helps engineers and product managers better understand and utilize this critical component.
Wichtigste Erkenntnisse
- Resonance Principle: Relies on resonant frequency for high efficiency and maximum amplitude.
- Speed Advantage: Fast response; start/stop requires only 10–50 ms.
- Feedback Quality: Delivers crisp, fine HD haptic feedback.
- Technical Requirement: Must use a dedicated driver IC with automatic frequency tracking.
- Market Position: The top choice for high-end products like smartphones and wearables
LRA Motor: Fundamental Principles & Structure
What is an LRA Motor?
An LRA motor is a linear vibrator. Its vibration does not come from rotation. It uses an internal mass block. This mass moves back and forth linearly within an elastic structure.
It differs from the common ERM (Eccentric Rotating Mass) motor. An LRA motor operates near a fixed mechanical resonant frequency. When the drive frequency, voltage, and mounting conditions are correctly matched, resonance increases the motion of the internal mass, enabling fast response and efficient, well-controlled haptic output.
LRA motors typically have a single vibration direction. They feature fast response and high control precision. They are ideal for applications demanding a high-quality haptic experience.
LRA Motor Structure
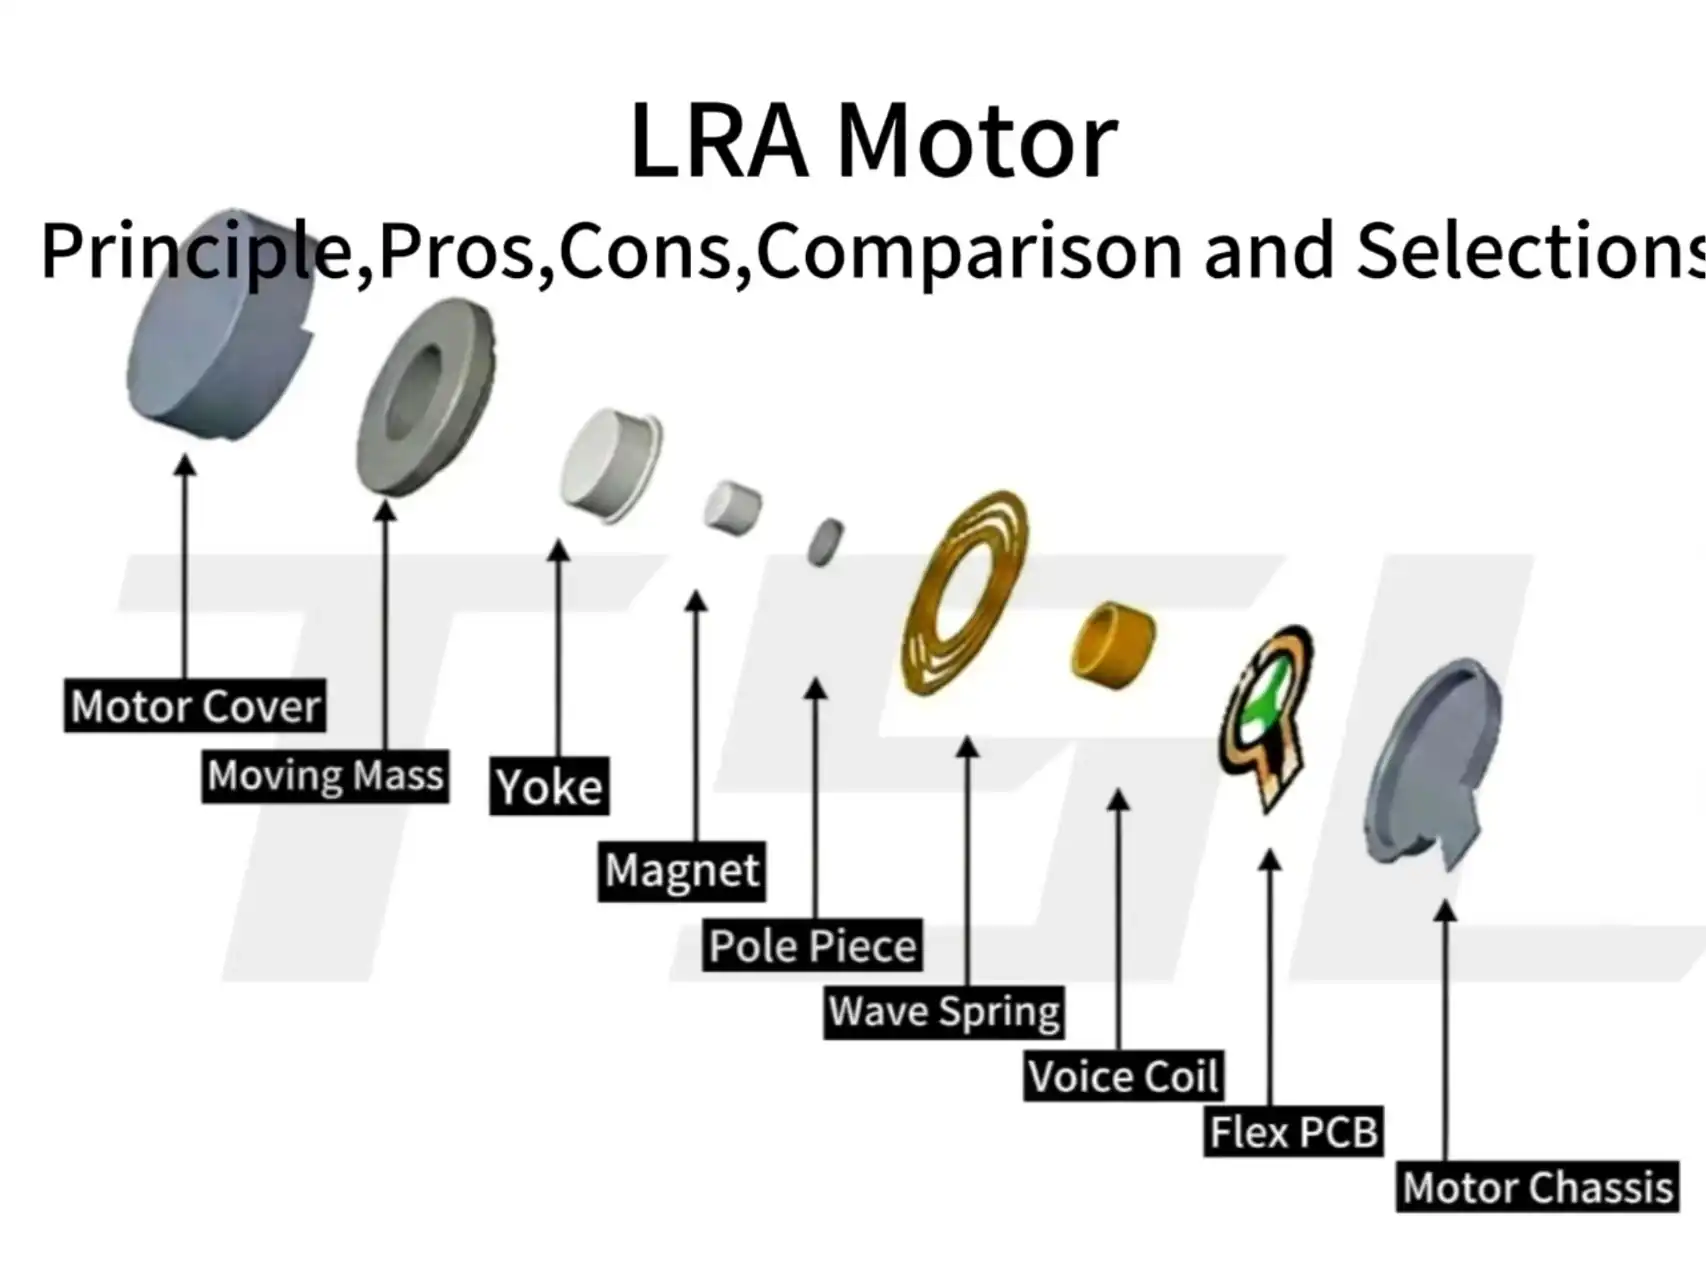
A typical LRA motor is encased in a compact metal shell. It consists of the following core components:
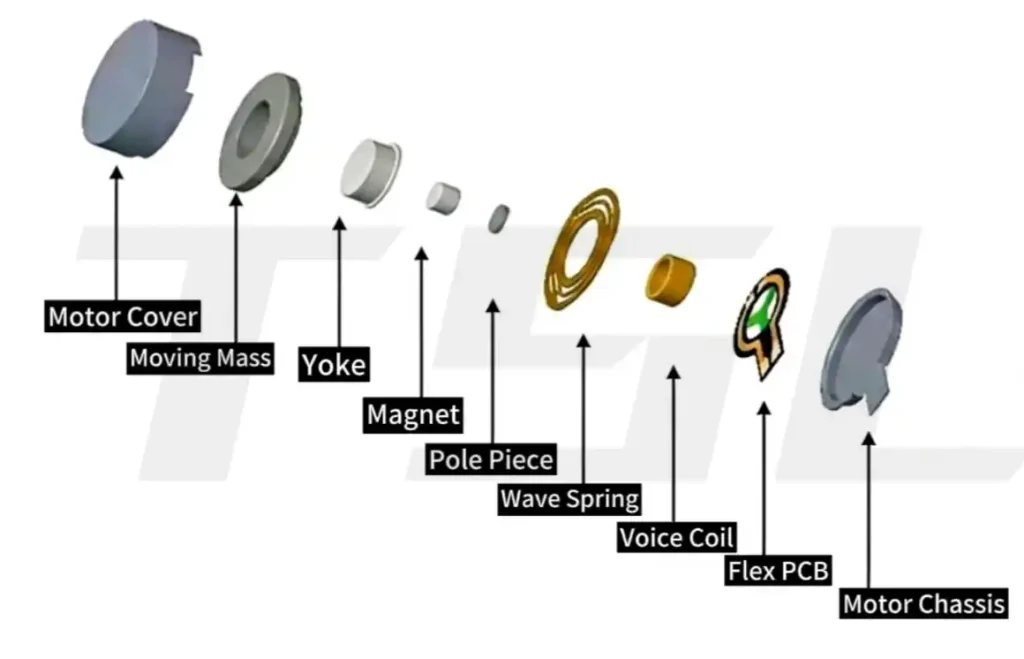
- Voice Coil: A copper winding that generates an alternating magnetic field when driven by AC. In many coin-type LRAs, the coil is fixed while the magnet and inertial mass move, although the arrangement can vary with the actuator design.
- Moving Mass: Usually made of NdFeB (Neodymium Iron Boron) high-energy magnets. Sometimes, a tungsten alloy block is added to increase mass. The inertia of the mass determines the maximum impact force (G-force).
- Spring Suspension: Suspends the moving mass centrally in the casing, allowing free vibration along a specific axis (Z-axis or X-axis). The stiffness of the spring and the mass together determine the resonant frequency. Common spring types include wave, leaf, or helical springs.
- Magnetic Circuit: Includes the permanent magnet and the yoke (magnetic conductor). Its role is to concentrate magnetic lines and improve the efficiency of electromagnetic energy conversion.
This architecture enables the LRA to work efficiently at a fixed resonant frequency. It balances low power consumption, fast response, and high-precision haptic feedback, making it widely used in smartphones, wearables, and VR/AR systems.
How Does an LRA Motor Work?
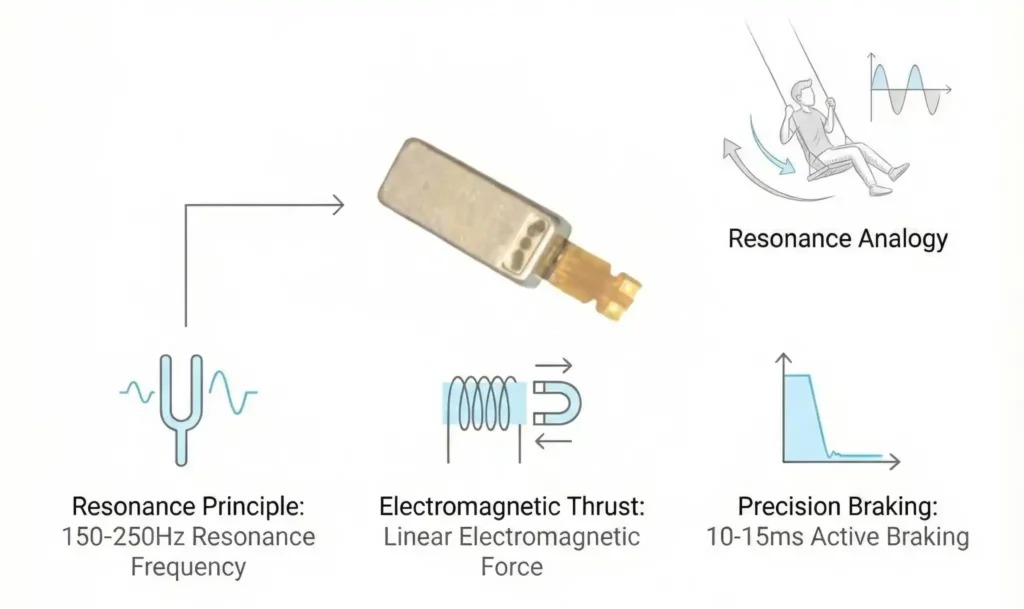
The LRA’s core principle is forced vibration at the resonant frequency. It is based on a spring-mass system. Simply put, it’s like pushing a swing. A small force applied at the correct time creates a large oscillation.
Step 1: Drive Signal Input
The controller sends a pulse signal to the LRA driver chip. This happens when haptic feedback is needed.
The signal frequency is usually 150–250 Hz. This matches the motor’s mechanical resonance point.
TSL MOTOR precisely tunes the frequency. Deviation is controlled within ±10Hz. This ensures consistent feedback across different devices.
Step 2: Electromagnetic Force Generation
The driver sends alternating current through the voice coil. As the current polarity reverses, the magnetic field interacts with the permanent magnet and produces force in opposite directions along the designed vibration axis, causing the moving assembly to oscillate.
In our experience, stronger magnets alone do not guarantee higher vibration output—the magnetic circuit, air gap, coil resistance, spring system, and drive frequency must work together.
Step 3: Resonance Amplification
The mass and spring system enters resonance. This happens when the drive frequency matches the system’s natural frequency.
Each thrust is applied at the opportune moment. Energy converts efficiently between the spring and the mass.
The result is a noticeable vibration. This is achieved with a very small driving force. It is like pushing a swing. A gentle push at the right time makes it swing higher and higher.
Step 4: Precise Braking
When the vibration needs to stop, the driver can apply active braking—such as a reverse-polarity pulse or short-circuit braking—to reduce the residual motion of the moving mass. With a correctly matched actuator and driver, this allows an LRA to stop more cleanly than a typical ERM motor and helps produce a crisp haptic effect without a long vibration tail.
Actual stopping time should be taken from the product test curve or datasheet rather than treated as a fixed 10–15 ms value. It can change with the actuator, drive waveform, mounting stiffness, enclosure damping, and measurement method.
Advantages of LRA Motors
The LRA Motor’s structure and principle offer unique advantages. These are key to haptic feedback. The benefits mainly lie in response speed, frequency control, haptic performance, and energy efficiency.
Millisecond-Level Response Speed
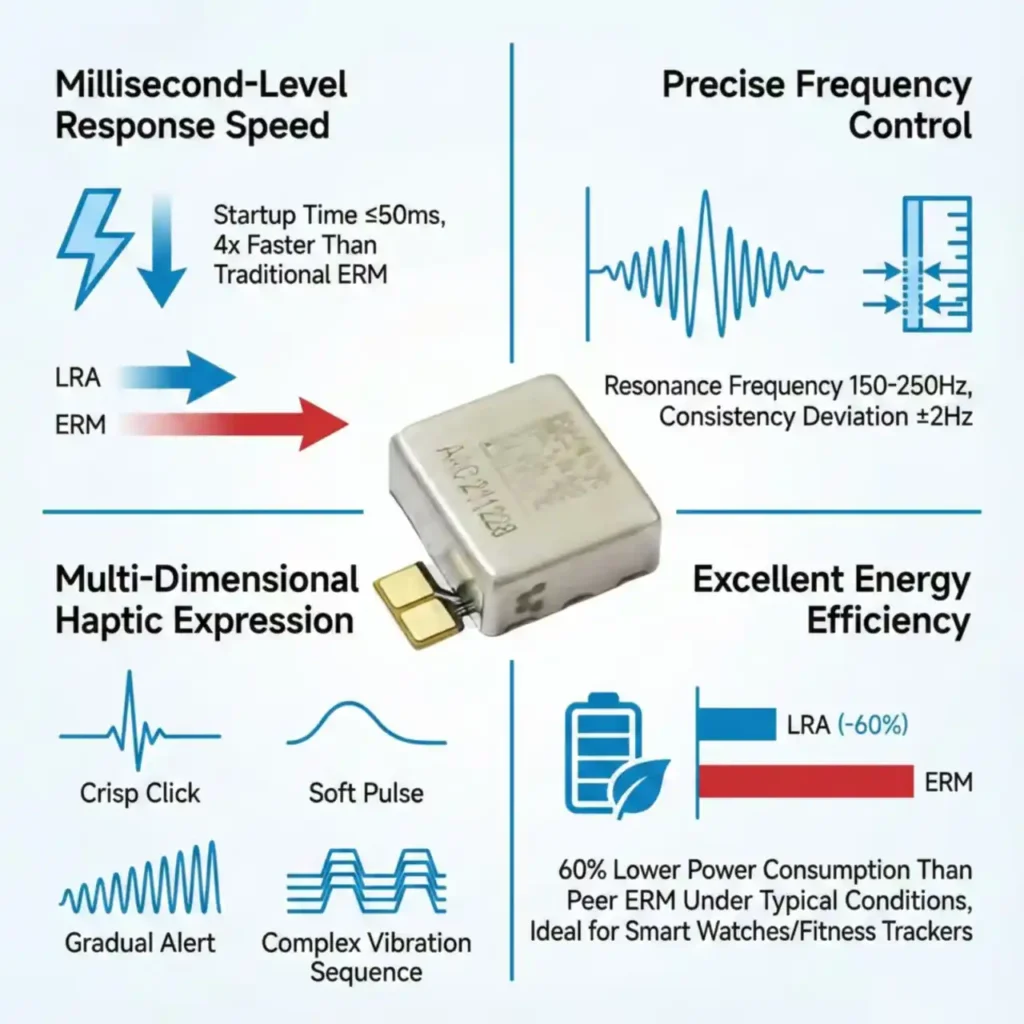
LRA motors can produce short, sharply defined effects when the actuator, drive waveform, overdrive, and braking are correctly matched. For example, the TSL-ELV208-175S specification lists rise and falling times of ≤50 ms under its stated measurement conditions. This is a model-specific test result rather than a universal response time for every LRA.
Texas Instruments’ haptic implementation guide also explains how overdrive and closed-loop braking can reduce actuator start and stop times. For a broader comparison of LRA, ERM, VCM, and piezo actuators, see our Haptic Motors Selection Guide.
Precise Frequency Control
The LRA operates at a fixed resonant frequency (typically 150–250 Hz). This maximizes vibration output with minimum energy input. Through precise tuning, frequency consistency is controlled within ±2 Hz. This ensures a uniform haptic experience across different devices.
Multi-Dimensional Haptic Expression
An LRA normally vibrates along a single mechanical axis, but the driver can shape the perceived feedback by adjusting amplitude, duration, repetition, overdrive, and braking. This makes it possible to create short clicks, double pulses, gentle alerts, and longer notification patterns rather than only a continuous buzz.
In this context, “multi-dimensional” describes a variety of programmable haptic effects—not physical movement along multiple axes. The available effects are still limited by the actuator’s resonant bandwidth, acceleration capability, mounting structure, and driver performance.
Excellent Energy Efficiency
An LRA can operate efficiently when driven near its resonant frequency because the spring-mass system produces useful acceleration with relatively limited electrical input. This makes LRAs well suited to battery-powered products that require short, repeated haptic events.
Comparison of LRA with Other Haptic Motors
The LRA’s greatest strength is its balance. It sits perfectly between the ERM’s low cost and the Piezo’s high performance. It delivers a cleaner, more efficient vibration than the ERM. It also avoids the high-voltage drive and complexity of the Piezo.
Table 1:Simple Comparison of LRA Motor and Other Haptic Motors
| Feature | LRA (Linear Resonant Actuator) | ERM (Eccentric Rotating Mass) | VCM (Voice Coil Motor) | Piezo Actuator |
| Principle | Mass block resonates on a single axis | Eccentric mass rotation | Non-resonant linear drive | Piezoelectric effect deformation |
| Response Speed | Faster (20–50 ms) | Slowest (100–200 ms) | Faster (non-resonant operation) | Fastest (<1 ms) |
| Energy Efficiency | High | Low | Medium | High / Very low (short bursts) |
| Vibration Quality | Crisp, precise, linear | Vague, "buzzing" | Very strong, more realistic | Extremely high, wideband, HD |
| Betriebsfrequenz | Narrow band (best at resonance) | Wideband (but single effect) | Wideband (high controllability) | Widest band (0–500 Hz) |
| Size/Thickness | Thinner / Compact | Larger (usually cylindrical) | Larger / Thicker | Extremely thin |
| Cost | Higher | Lowest | High | Highest |
| Drive Requirement | Dedicated IC | DC voltage | drive and control | tens to hundreds of volts |
Versus ERM (Eccentric Rotating Mass)
ERM relies on a motor rotating an eccentric mass. This generates vibration.
- LRA Advantages: Faster response, higher efficiency, finer vibration, longer lifespan.
- ERM Advantages: Simple structure, lowest cost, strong vibration. It is still used in low-end applications.
Versus VCM (Voice Coil Motor)
VCM is similar to LRA. It is also a linear drive. But it is usually designed for non-resonant or wideband operation.
- LRA Advantage: Higher efficiency at its resonant frequency.
- VCM Advantage: VCM works better over a wider frequency range. It offers richer, more realistic haptic experiences. But it generally requires a larger size and higher power consumption. In high-end phones, LRA performance is approaching VCM. Some LRAs can even achieve wideband or dual-frequency operation.
Versus Piezo Actuator
Piezo actuators generate vibration through piezoelectric material deformation.
- LRA Advantages: Low drive voltage (LRA needs only a few volts; Piezo needs tens to hundreds of volts). Lower cost. Easier drive circuit design.
- Piezo Advantages: Extremely fast response (millisecond level, tens of times faster than LRA). Wide operating frequency band. It achieves the finest, highest-fidelity haptic effects (true HD Haptics). It can be made very thin.
- Main Piezo Drawbacks: High-voltage drive requirement and higher cost.
Limitations of LRA Motors
Despite their many advantages, LRA motors have limitations. These mainly focus on the frequency bandwidth restriction. This leads to insufficient haptic diversity. Drive circuit complexity is also a factor.
These limitations make LRA inferior to wideband, ultra-fast Piezo actuators. This is true in scenarios needing the highest fidelity haptics (e.g., advanced VR, medical haptics).
Narrow-Band Operation (Resonance-Limited Bandwidth)
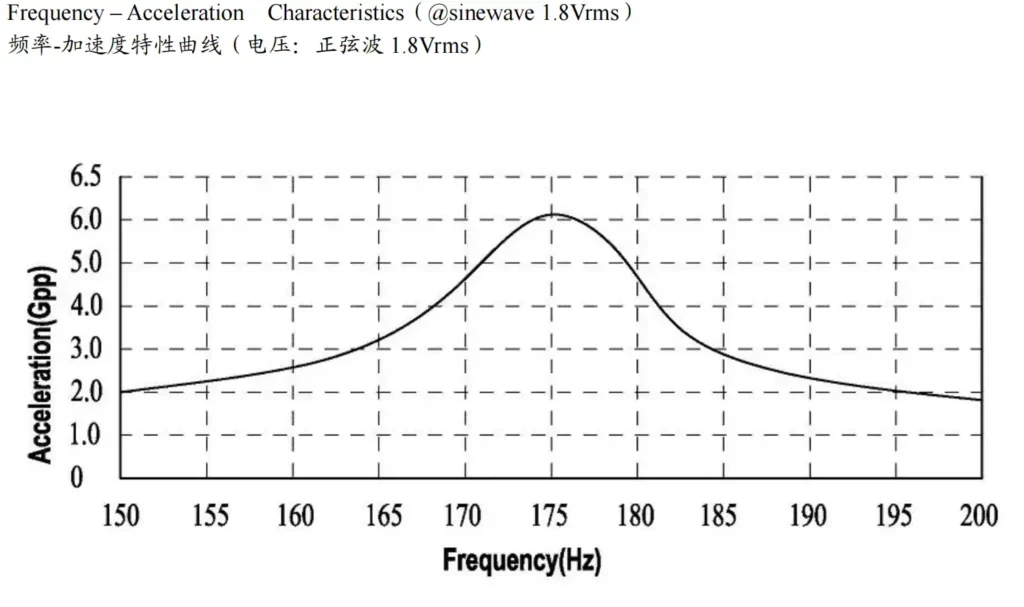
Narrow operating frequency range: The LRA is most efficient near its natural resonant frequency, typically 150–200 Hz.
High-performance loss: Vibration intensity drops sharply when the drive frequency deviates. A 10% deviation can cause a 30% or greater loss.
Limited haptic effect: It is hard to maintain a consistent haptic experience over a wide frequency range. This limits the diversity of HD Haptics and complex waveforms.
Resonant Frequency Drift
Environmental impact: Temperature, mounting, and casing damping can cause the optimal resonant frequency to drift.
Drive complexity: Dedicated drive chips (Haptic Driver IC) are required. They monitor back-EMF (BEMF) and automatically track the frequency in real-time.
Increased cost: The LRA drive circuit is more complex. This compares to ERM (only needs DC power) or Piezo (simple drive but needs high voltage).
Requires Moving Mass
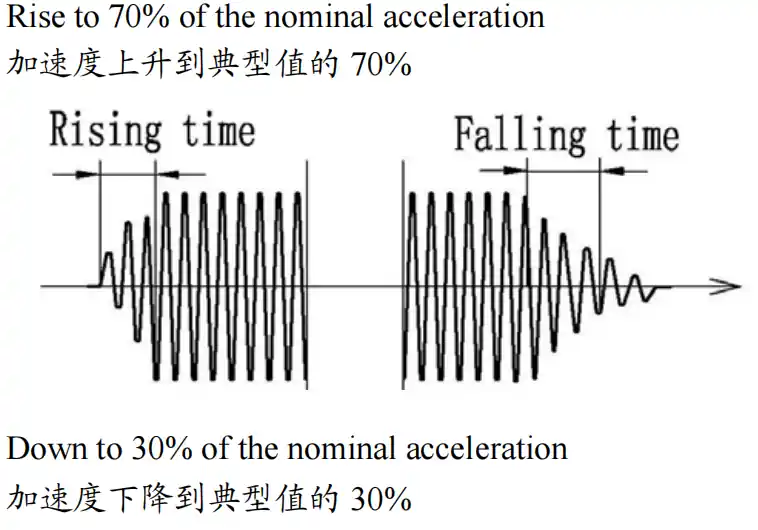
Response speed limited: Startup time is about 20–50 ms. It is faster than ERM, but slower than Piezo actuators (<1 ms).
Larger size: It requires a mass block, spring, and magnetic structure. The thickness is usually greater than very thin Piezo actuators.
Relatively Higher Cost
Higher than ERM: Design and manufacturing require greater precision, and a dedicated drive chip is also necessary.
Increases system BOM: While a single LRA might be cheaper than a Piezo, the drive chip and mounting requirements increase the overall system cost.
LRA Motor Applications
The LRA is quickly replacing traditional ERM motors. This is due to its fast response, fine haptic feedback, and high efficiency.
LRA is now the mainstream choice in consumer electronics. This includes smartphones and wearables. These devices demand a higher-quality haptic experience.

Consumer Electronics
This is the primary application area for LRA motors. They provide Haptic Feedback. This enhances the user interaction experience:
- Smartphones and Tablets: Vibration alerts for calls, texts, or notifications. Realistic “click feel” for virtual buttons, keyboard input, and scrolling. (Apple’s Taptic Engine is a typical LRA application.)
- Game Controllers: Simulation of immersive haptic effects. This includes explosions, impacts, shooting, and friction. It enhances immersion.
- Wearable Devices: Notification alerts and alarms for smartwatches and fitness trackers.
- Laptop Touchpads / Capacitive Pens: Simulation of physical button clicks. Provides precise pressure feedback.
Virtual / Augmented Reality (VR/AR)
In VR/AR systems, LRA creates a more realistic immersive experience. For VR headsets and controllers, LRA Motors simulate different sensations. Examples include grabbing objects, touching surfaces, or being injured.
Automotive Systems
LRA is entering the automotive electronics field. It is used to improve the driving and operation experience:
Dashboards and Center Consoles: Provides haptic feedback on touchscreens or touch buttons. This confirms operations and improves safety.
Medical and Precision Instruments
LRA is also used in high-precision equipment. This is thanks to its good dynamic response and precise control. For example, in precision instruments, the LRA motor is chosen for high-accuracy control.
How to Select the Right LRA Motor
When selecting an LRA, several factors must be considered. These include resonant frequency, rated voltage and current, vibration intensity (G-value), size/form factor, and mounting method. The availability of a suitable driver IC must also be confirmed. These factors directly affect the haptic experience and development efficiency.
Resonant Frequency
Definition: The LRA must operate near its natural resonant frequency to maximize amplitude and efficiency.
Selection Range:
- High Frequency (170–200 Hz): Vibration feels clearer and sharper. Suitable for fine interactions on phones and tablets (e.g., key clicks, virtual keyboard input).
- Low Frequency (100–150 Hz): Vibration feels deeper and stronger. Suitable for game controllers or strong alert scenarios.
Drive Requirement: Resonant frequency may drift with temperature and mounting. An automatic resonant frequency tracking driver IC must be used to ensure operation at the optimal efficiency point.
Vibration Intensity (G-Value / Acceleration)
Definition: G-value represents the vibration amplitude’s acceleration, measured in G (≈ 9.8 m/s²).
Selection Range:
- High G-value (≥ 2 G): Suitable for immersive experiences or strong warnings (e.g., game controllers, industrial control).
- Medium-Low G-value (1.0–1.5 G): Suitable for most consumer electronics (e.g., phones, watches). Provides clear and comfortable feedback.
Power Relationship: G-value is proportional to drive voltage. A driver IC is usually required to boost system voltage (e.g., from 3.3 V to 5–8 V) to achieve higher G-values.
Drive Solution and Power Matching: The System Core
AC Drive: The LRA is an AC-driven device and requires a dedicated driver IC.
Driver IC Functions:
- Provide a sine or square wave matching the resonant frequency.
- Boost voltage to meet high G-value demands.
- Track frequency to ensure efficiency.
- Offer built-in waveform libraries to simplify software development.
Matching Principle: Ensure the LRA’s rated voltage and maximum drive current fully match the driver IC’s output capability and the system’s power budget.
Size, Form Factor, and Mounting Method
Form Factor Options:
- Coin Type: Suitable for products requiring extreme thinness (e.g., smartwatches).
- Bar Type: Suitable for devices needing higher G-values and allowing more space (e.g., smartphones).
- Cylindrical Type: Suitable for wider frequency ranges and devices with ample space.
Mounting Requirement: The LRA must be firmly fixed to the device casing or a rigid frame to efficiently transfer vibration energy. Any looseness or mounting on a soft bracket significantly reduces the perceived G-value.
Solution: TSL MOTOR provides optimized mounting solutions to prevent performance loss due to structural design issues.
TSL MOTOR Support as an LRA Motor Manufacturer
We specialize in LRA motor R&D and manufacturing. We offer a variety of standard models. These cover different sizes, resonant frequencies, and vibration intensities.
We also offer custom development. This includes structural size optimization, frequency parameter tuning, and performance enhancement.
Our support is mainly in these areas:
- Rich Product Line: We offer products from coin to bar type. From low to high frequency. From medium-low to high G-value. This meets the needs of smartphones, wearables, game controllers, automotive electronics, and medical instruments.
- Custom Development Capability: We adjust motor size, resonant frequency, and drive characteristics. This is based on the customer’s product structure and interaction needs. We ensure the best haptic experience.
- Drive and System Support: We recommend matched drive ICs and provide reference designs. This helps customers shorten development cycles. It also lowers system integration risk.
- Consistency and Reliability Testing: Strict batch consistency control and long-term reliability validation. This ensures stability and consistency during mass production.
- Full-Process Technical Support: We offer professional engineering support. This covers product validation and mass production phases. It includes selection consultation, mounting solution optimization, drive debugging, and performance evaluation.
We are more than an LRA motor manufacturer. We are a haptic solution partner. We combine standardized products with customized services.
We help customers achieve the best haptic feedback. This is for various application scenarios. We ensure development efficiency and system reliability.
Fazit
Die LRA Motor (Linear Resonant Actuator) is dominant. This is thanks to its unique resonant working principle. It leads the rapidly growing global haptic feedback market.
Its core value is in finding the best balance. This balance is between high response speed, high efficiency, and fine haptic experience. It is far superior to traditional ERM motors. It avoids the high-voltage drive and complexity of Piezo actuators.
The LRA faces challenges: narrow-band operation and resonant frequency drift. However, these limitations can be overcome. This is done with dedicated driver ICs that feature automatic frequency tracking. Professional structural design optimization also helps.
Selecting the LRA motor and the right drive solution is crucial. This is for smart hardware manufacturers aiming for premium interaction experiences.
TSL MOTOR is committed to helping global customers. We provide a diverse product line and strong customized technical support.
We help overcome design challenges. We ensure the integration of high-performance, highly reliable haptic feedback. This is for their next-generation products. The LRA is more than a component. It is key to enhancing user immersion and device premium feel.
FAQ
Q1: What is the biggest difference between LRA and ERM?
LRA operates based on the principle of resonance, offering fast response times (20–50 ms) and high energy efficiency. In contrast, ERM uses rotation, resulting in a slower response (100–200 ms) and higher power consumption.
Q2: How does the LRA motor work?
The LRA generates an alternating electromagnetic force through its voice coil and permanent magnet. This force drives the mass block to oscillate linearly at its natural resonant frequency, amplifying the vibration.
Q3: Why does an LRA require a dedicated driver IC?
LRAs operate within a narrow frequency band. The dedicated IC is necessary to output the precise AC signal, enable automatic frequency tracking, and perform voltage boosting to ensure optimal efficiency and maximum performance.
Q4: What are the main limitations of LRA motors?
Their operating frequency range is relatively narrow (near $F_0$). The resonant frequency is also prone to drift due to changes in temperature and mounting conditions.
Q5: What are the primary applications of LRAs?
Key applications include smartphones (for crisp click sensations), wearable devices, and game controllers, where they are used to deliver high-quality haptic feedback.
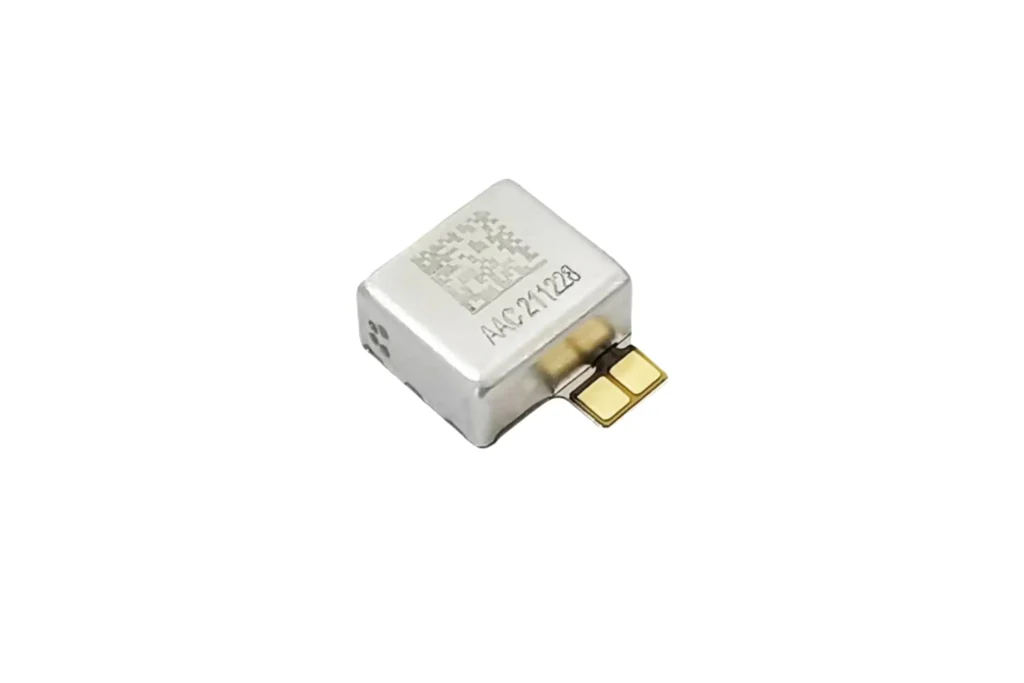
Linearer Resonanzaktuar
TSL offers high-performance Linear Resonant Actuators (LRAs), designed to provide precise and efficient haptic feedback for a wide range of applications. LRAs are typically used in mobile devices, wearables, and automotive systems, offering excellent performance in terms of vibration intensity and energy efficiency. Our LRAs come in the following types:Standard LRAs,Miniature LRAs and Custom LRAs.TSL supports custom designs to fit your exact requirements, ensuring optimal user experience and seamless integration into your products.